
Earlier research
Hexapod mechanisms and gaits
The HX1 page documents an earlier research prototype, including its mechanism, reference specifications, gait demonstrations and associated publication.
Explore the researchOriginMind / About us
Developing quadruped inspection robots and software for mining.
OriginMind develops quadruped inspection robots and OmindOS software. Our work draws on underground metal mine research, with a focus on mobility, sensing, inspection records and task validation.
The Q1 quadruped inspection platform is at the engineering prototype stage. We work with industry teams and integrators to assess site conditions and plan validation, alongside research into wheeled, dual-arm and educational platforms.
Research collaboration
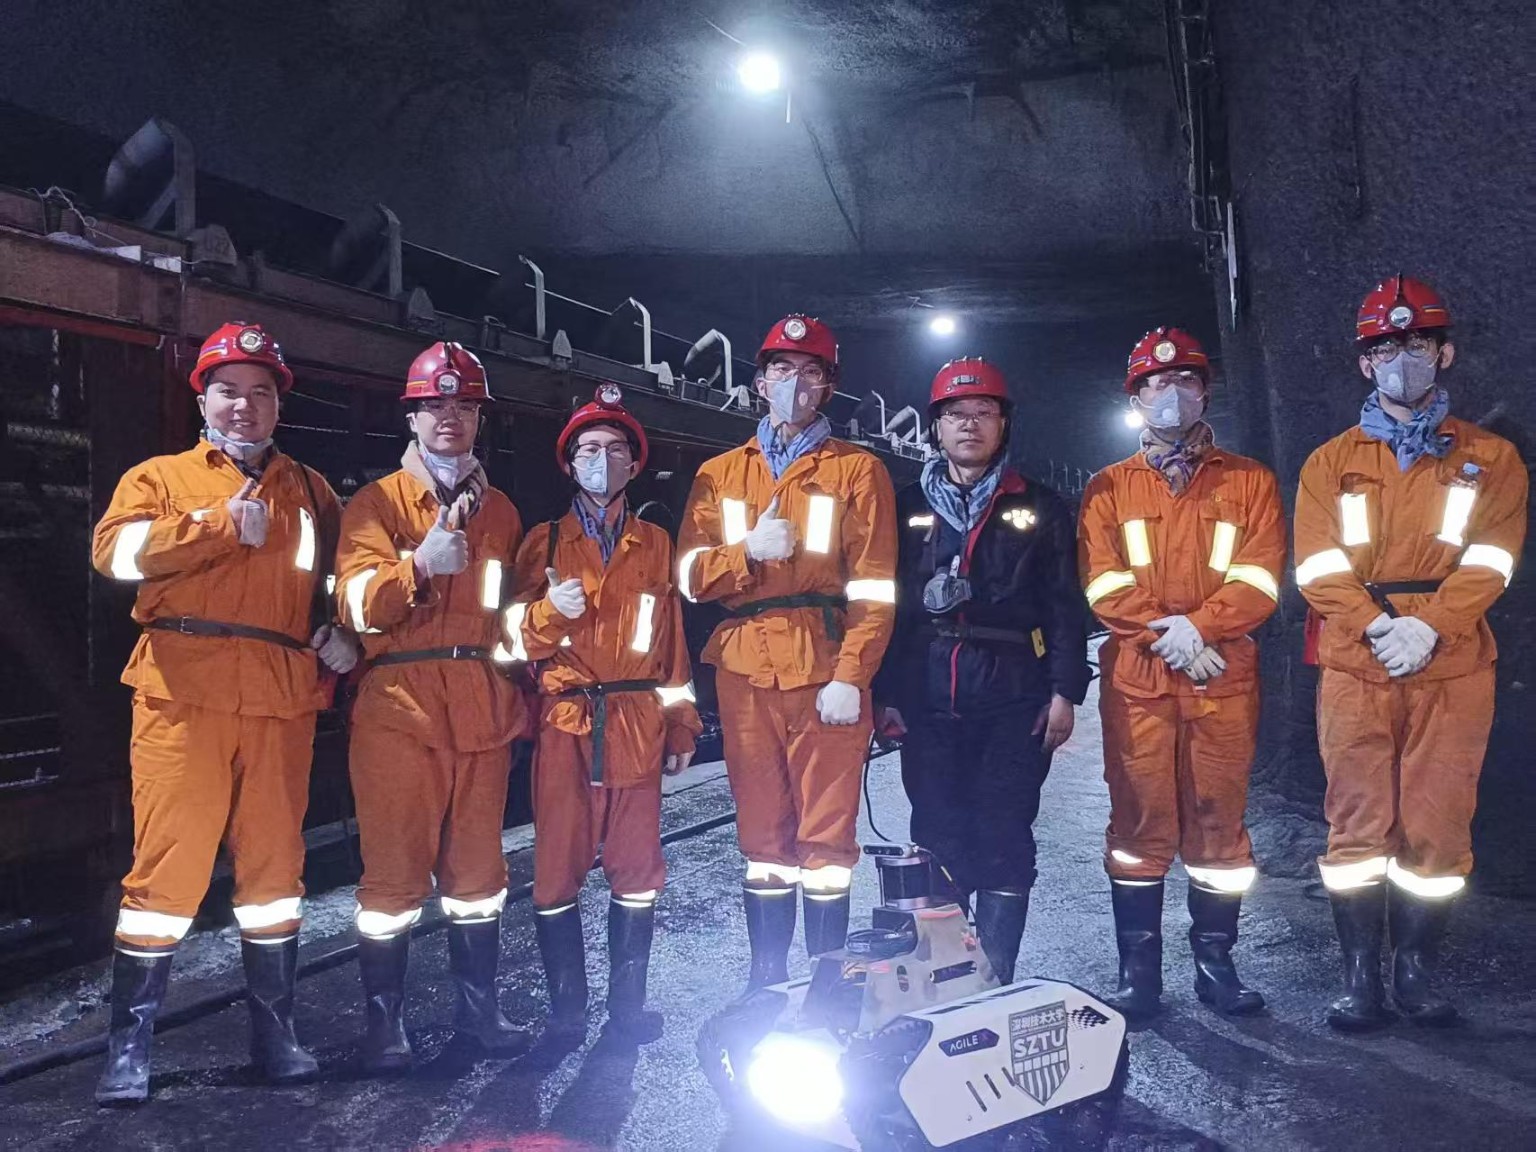
We collaborate with ARTS Robotics, the autonomous locomotion and manipulation laboratory at Shenzhen Technology University, on robotics research and field demonstrations.
Research spans robot mobility and manipulation, embodied intelligence, mapping, navigation and control.
We also develop platforms for robotics research and education.
Watch the demonstrations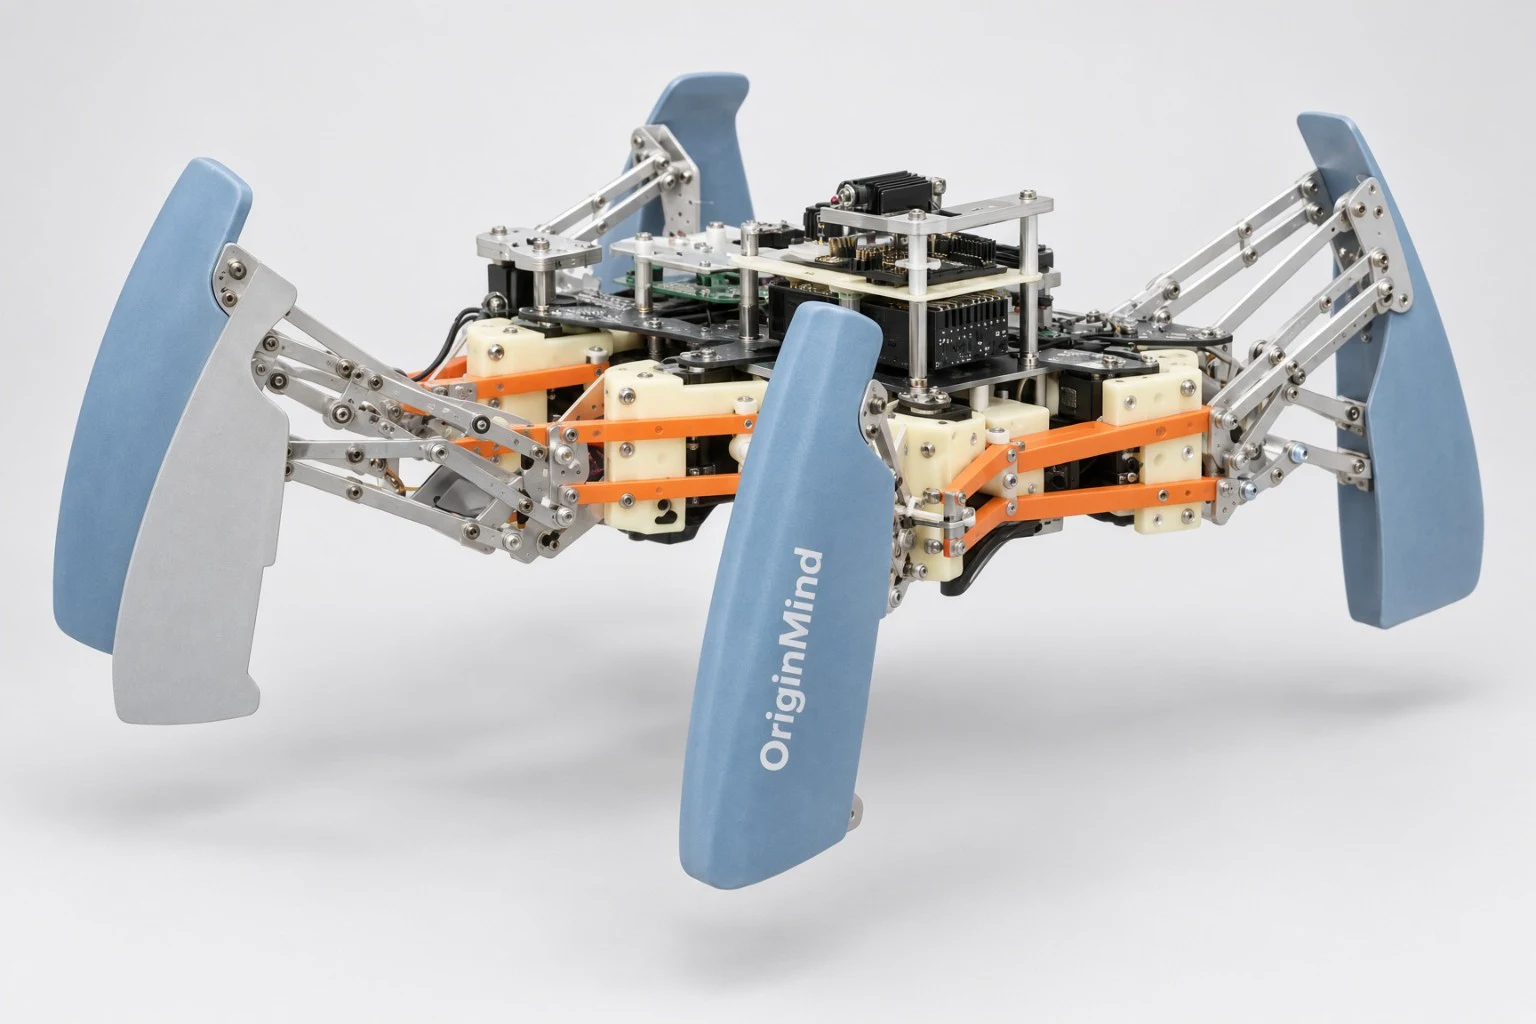
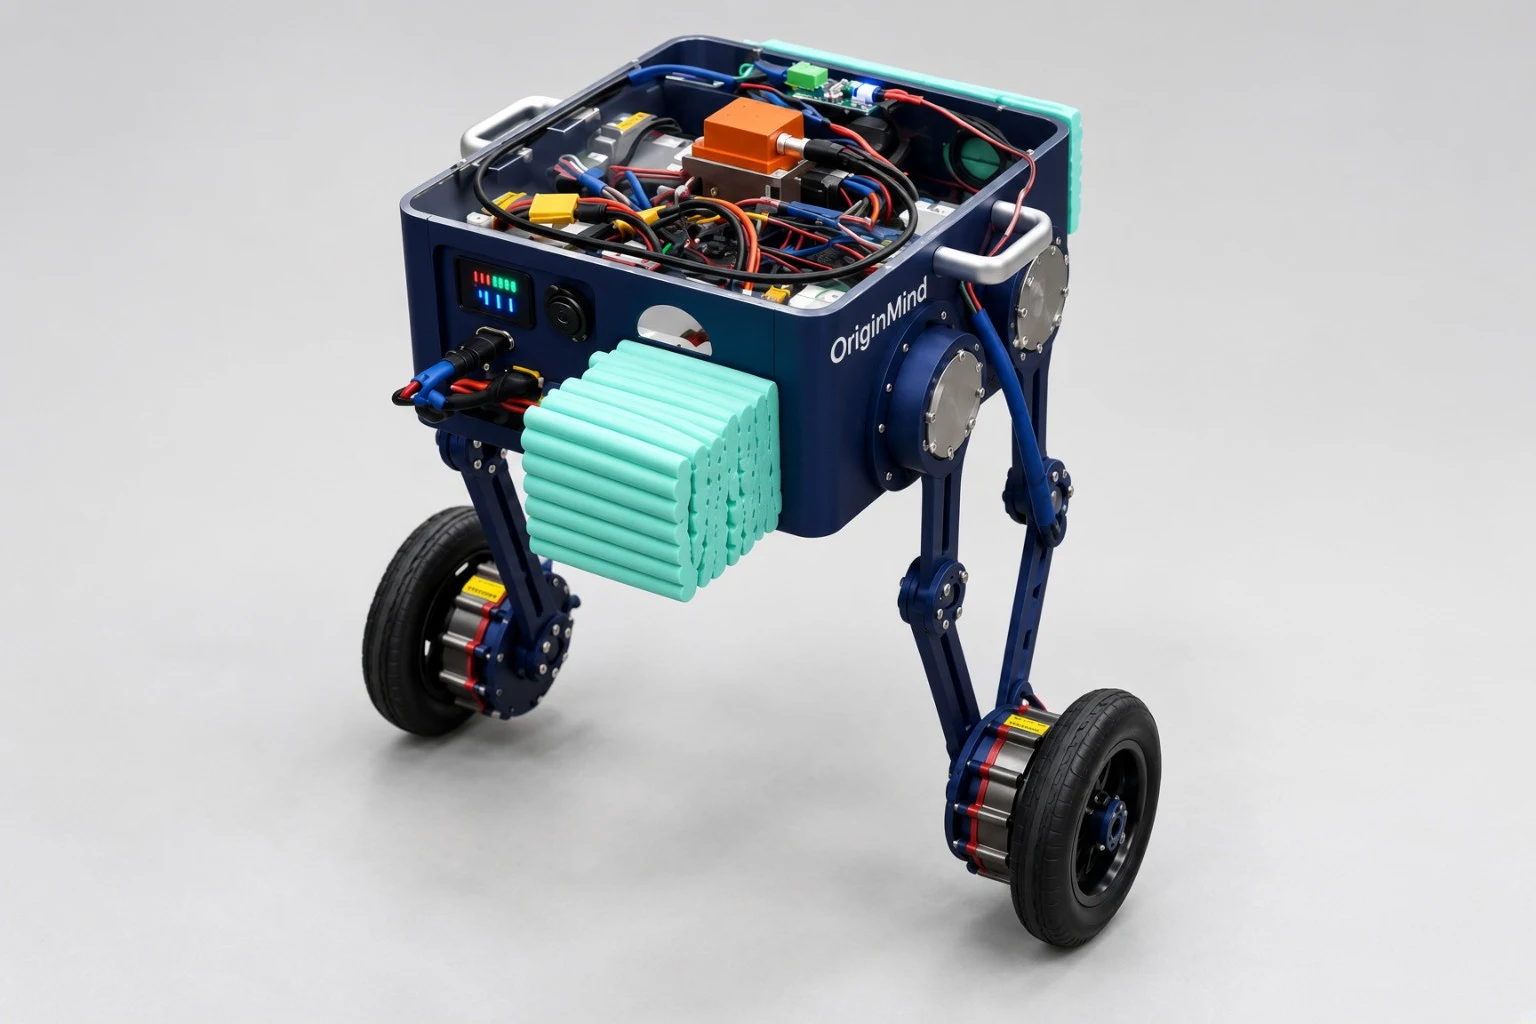
Explore the research, underground field work and robot experiments behind our development.
Earlier research
The HX1 page documents an earlier research prototype, including its mechanism, reference specifications, gait demonstrations and associated publication.
Explore the researchManipulation experiments
Watch cup handling, pouring and synchronization between a virtual model and physical robot arms.
Watch dual-arm demonstrationsUnderground field work
Explore multi-sensor localization, 3D reconstruction and semantic inspection research, alongside recordings from an underground metal mine.
Explore underground field work