
Design and assembly
Use the exploded-view animations to examine the wheel-and-leg mechanism, component layout and assembly.
Explore the designOriginMind · Education and research
WL1-EDU combines coordinated wheel-and-leg motion with an enclosed body for motion-control research and hardware integration experiments.
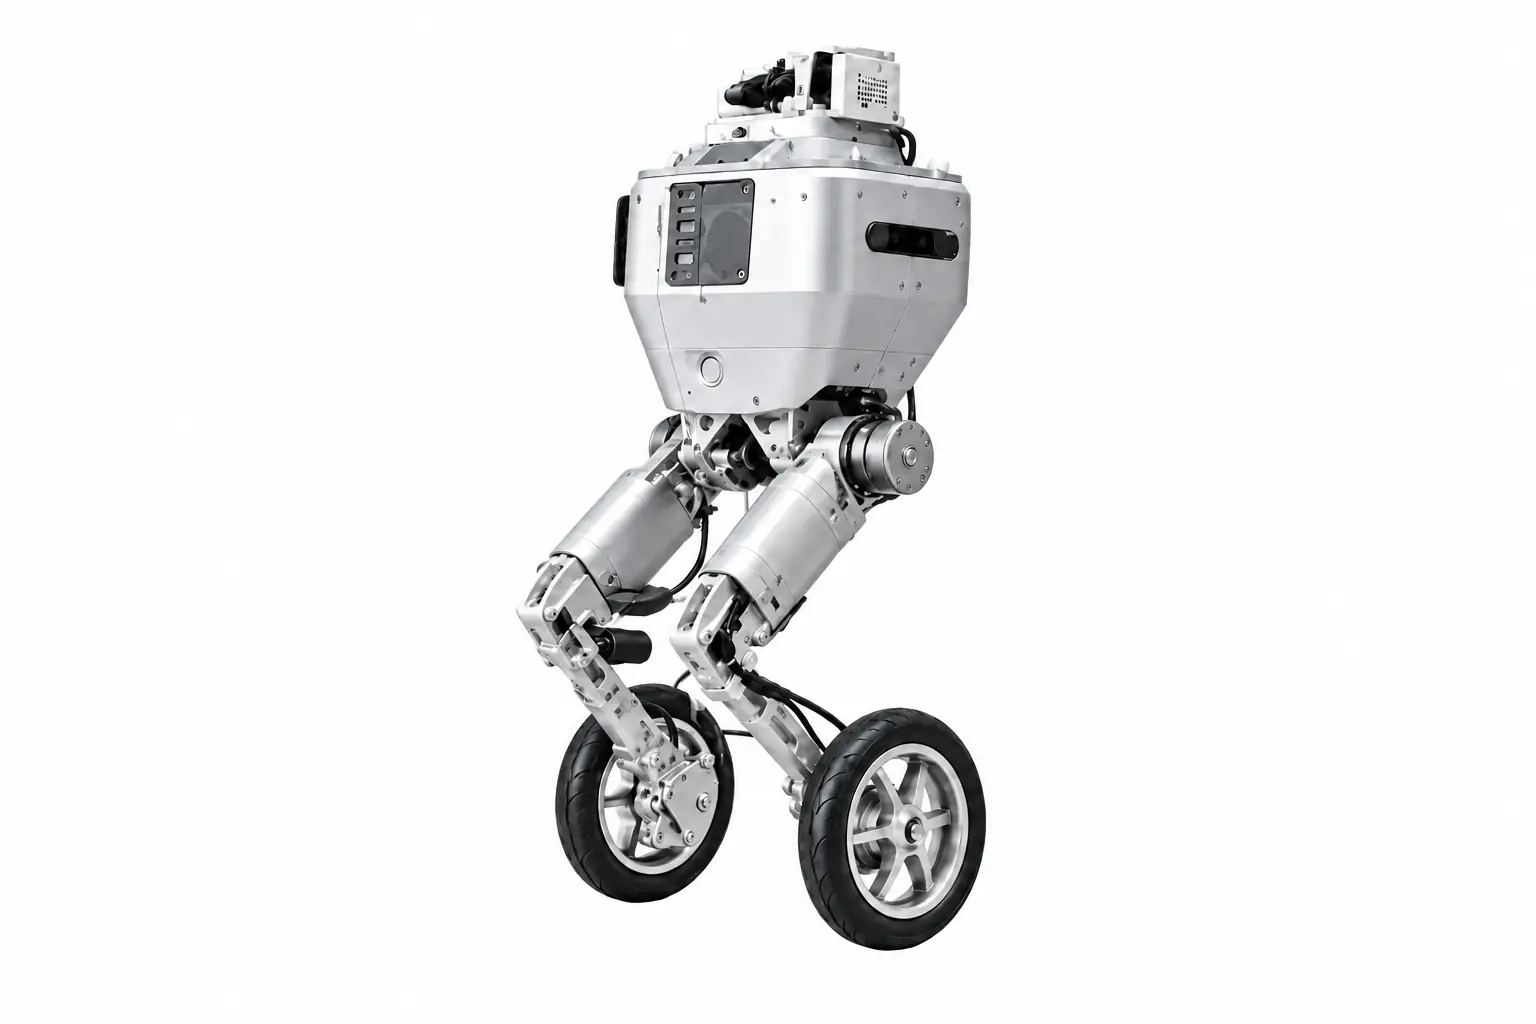
Prototype
| Robot type | Wheel-legged |
|---|---|
| Body | Enclosed body |
| Research applications | Wheel-and-leg coordination, hardware integration and prototype testing |
| Integration assessment | Sensors, onboard computing, power and communications interfaces |
An education and research prototype for teaching, demonstrations and experimental validation.
Discuss research collaborationThe enclosed body houses onboard equipment, while wheel drives and leg joints work together to produce motion.
The animations show development-stage designs. Appearance and components may differ from the rendering; refer to the specific prototype for its mechanical configuration.
Study coordinated motion through wheel drive and leg-joint posture control.
Recorded demonstrations show corridor travel, maneuvering and outdoor movement. Confirm control interfaces and performance data for the specific prototype.
Assess camera, LiDAR and computing integration to provide perception inputs for motion-planning research.
Check mounting space, payload, power and communications before integration. Perception and planning functions require validation on the specific prototype.
Share the target tasks, site conditions and equipment you plan to install so we can define integration requirements and validation scope.
The footage shows corridor travel, maneuvering and outdoor movement in test environments. Terrain capability depends on the ground surface, slope and task payload.
Plan experiments using the mechanical design, recorded demonstrations and robotics courses.
Use the exploded-view animations to examine the wheel-and-leg mechanism, component layout and assembly.
Explore the designExplore robotics fundamentals, control methods and system integration alongside the platform designs and task demonstrations on this page.
Explore robotics courses (Chinese)Observe straight-line travel and turns. Record posture, speed and ground conditions to compare wheel-and-leg coordination.
Watch demonstrationsControl software, interface documentation and example code for this model are being prepared. Before operating hardware, confirm the instructions and interface definitions for the specific prototype.