
Underground perception and localization
Research combines camera, LiDAR and inertial data for mapping, localization and object recognition underground, where satellite positioning is unavailable.
Core platform · Mine inspection
Q1 is in development for navigation through mine passages and equipment inspection, combining research into quadruped mobility, perception and task execution with OmindOS inspection software.
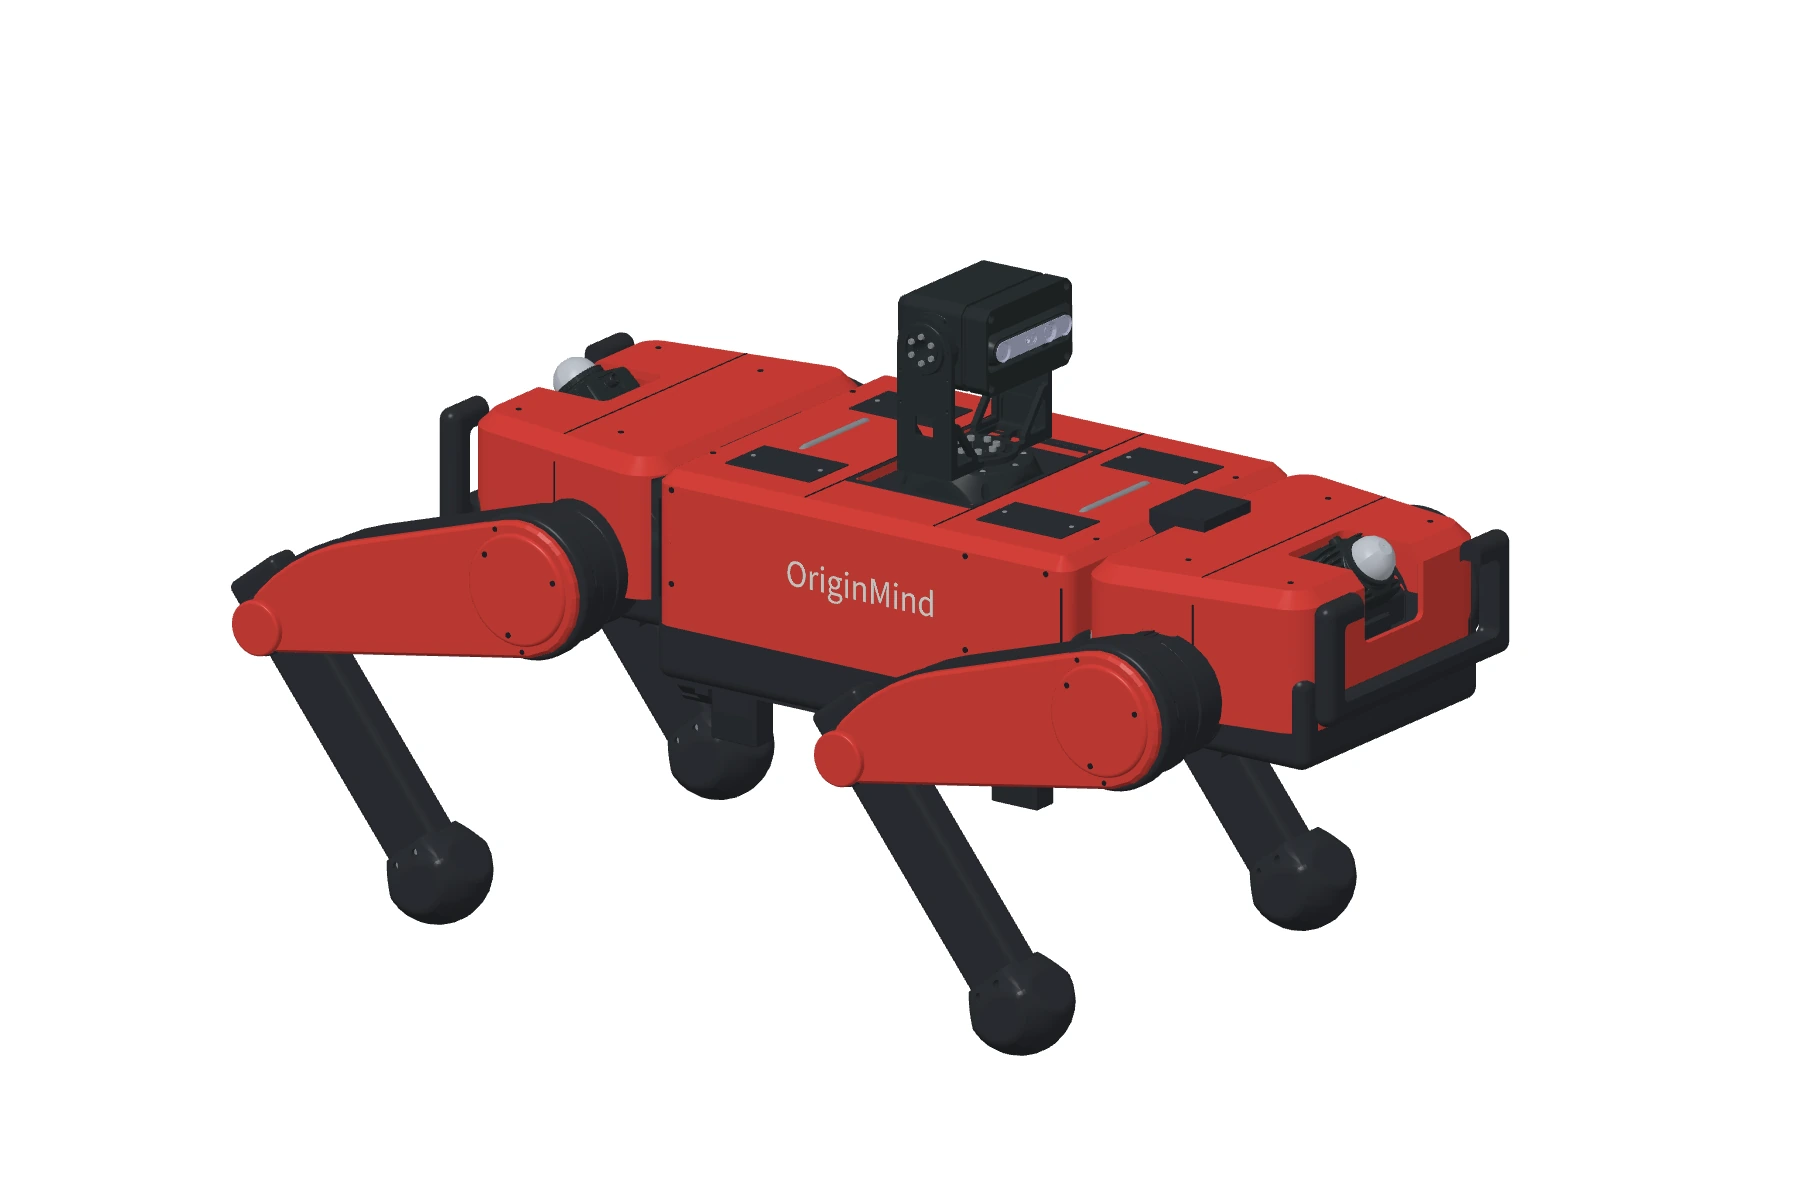
Platform overview
| Robot type | Quadruped |
|---|---|
| Development focus | Mine inspection |
| Development status | Engineering prototype in development |
The rendering shows the robot and sensing assembly design. Q1 is not currently available for sale.
Ask about developmentOmindOS Cloud · Q1
A 30-second offline dynamics run using the Q1 R2 model and MuJoCo 3.3.7, rendered in 1080p with the V1.3 exterior. The target speed for this run is 0.40 m/s.
Reference settings: target speed 0.40 m/s, foot clearance 0.020 m, gait period 1.5 s, and stance ratio 0.90. Including acceleration, the simulated robot travels approximately 11.24 m, with a peak tilt of approximately 3.01°.
Software simulation only. Mass, inertia, contact and actuator parameters still require physical calibration. These results are not measured prototype performance.
The server runner extends the speed limit to 0.40 m/s. An independent rerun reproduced the recorded results; mean forward speed from 3 to 30 seconds was approximately 0.401 m/s. This does not establish constant-speed or general operating performance.
The public ROS2 release (PR #30) accepts 0.02–0.16 m/s and retains a built-in stable crawl setting of 0.04 m/s. Cloud parameter runs last 7 seconds and are recorded separately from this 30-second offline run. End-to-end native ROS2 service, topic and stop-flow acceptance at 0.40 m/s remains incomplete.
Peak torque reached the model limit of 60 N·m. At least one actuator reached 59.9 N·m in approximately 7.2% of physics steps. Mass, inertia, contact and actuator parameters still require hardware calibration.
View the validation record · ROS2 parameter documentation (Chinese)The earlier Q1 demonstration is retained. Its on-screen readings are separate from the R2 dynamics simulation above.
Development follows the inspection workflow: reach a location, capture data, retain the record and support human review. Integration of the quadruped platform and software is being validated in stages.
Research combines camera, LiDAR and inertial data for mapping, localization and object recognition underground, where satellite positioning is unavailable.
Research combines spoken or written instructions with visual information to translate inspection requests into navigation goals and task steps.
Validation connects path planning and quadruped control for slopes, obstacles and uneven ground in mine passages.
Research connects scheduled, waypoint and route-based tasks with visible-light, thermal and other inspection data capture.
Development brings robot status, site imagery and 3D maps into one view, with research into remote monitoring and operator intervention.
Research links timestamps, locations, imagery and task states while retaining original records for review and follow-up.
Existing work covers multi-sensor localization, scene reconstruction and semantic inspection, with field records from several mobile platforms.
Explore the researchQ1 renderings and quadruped motion simulations illustrate the current structural and motion designs.
Watch the simulationValidation will focus on whole-robot motion, task payload, power and runtime, site communications and inspection workflows.
Discuss validation requirements| Mobility platform | Quadruped robot |
|---|---|
| Sensing development | Camera, LiDAR and inertial data fusion; inspection sensors assessed for each task |
| Software development | OmindOS integration, task planning, remote monitoring and inspection data management |
| Validation priorities | Whole-robot motion, payload and power, site communications and task execution |
| Site conditions | Test plans based on terrain, dust, moisture, lighting and communications coverage |
| Protection and certification | No ingress-protection rating, explosion-protection certification or suitability for special operating conditions is claimed |
Dimensions, weight, runtime and terrain capability have not yet been validated and are not published as product specifications. Suitability for a particular operating area requires review of whole-robot tests, certification documentation and site requirements.
Discuss development progressDefine the operating area and inspection targets first, then assess configuration, operating conditions and field validation scope.
Assess mobility, perception and communications for uneven ground, restricted routes and equipment observation points.
Assess imagery, temperature monitoring and record requirements at equipment observation points. Detection capability must be validated for the sensor configuration.
Work with integrators and operators to define tasks, sensors, payloads and system integration requirements.
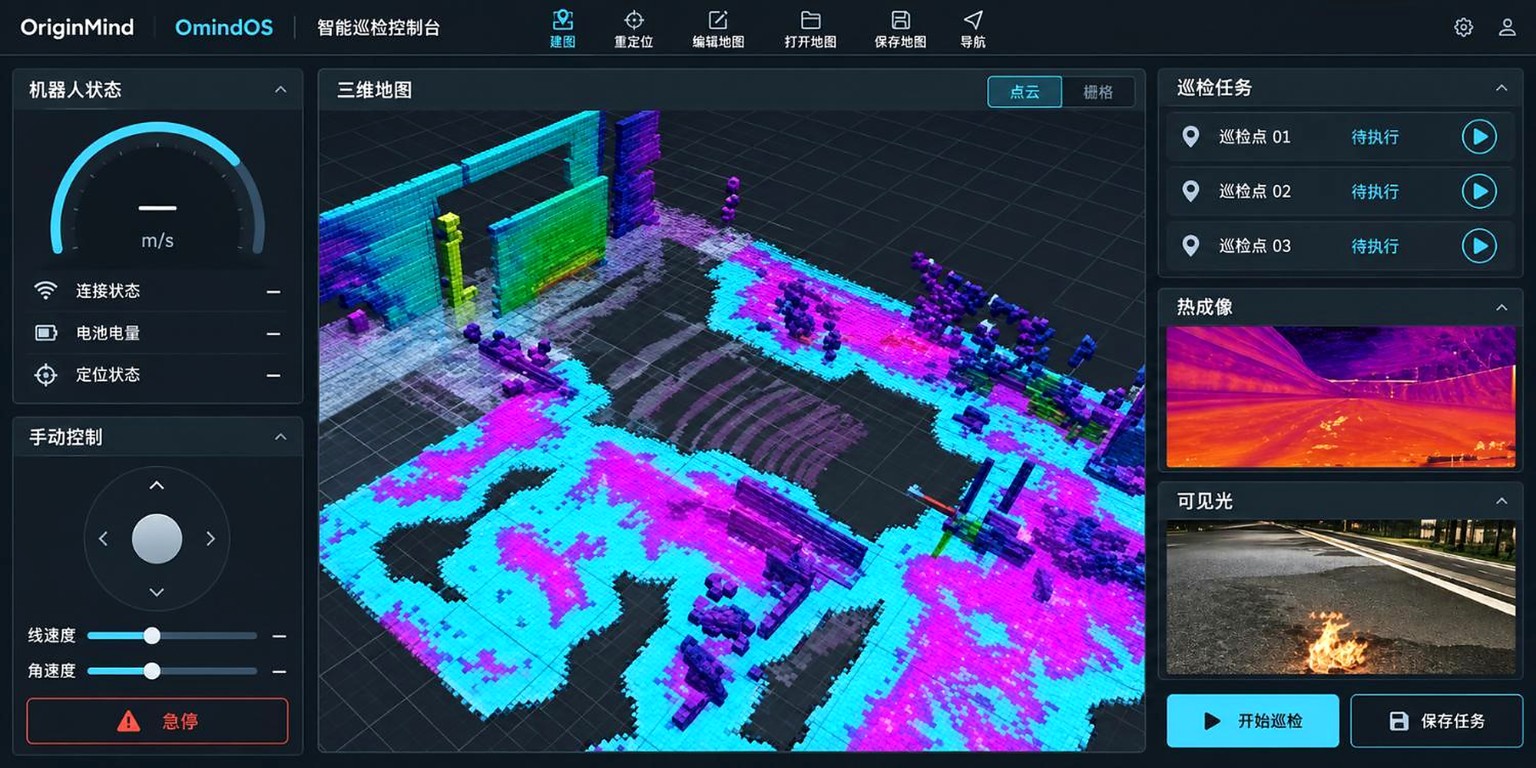
The interface organizes robot status, 3D maps, inspection points and site imagery. Functions will be integrated with the quadruped platform and validated as development progresses.
Application requirements
Tell us the mine type, operating area, inspection route and targets, together with the records you need or the outcomes you want to validate.
Contact the team