
Base positioning
Move the base to the target position and align it to establish a stable starting point for dual-arm operation.
OriginMind · Industrial
A mobile base with two robotic arms for research into mobile grasping and coordinated manipulation.
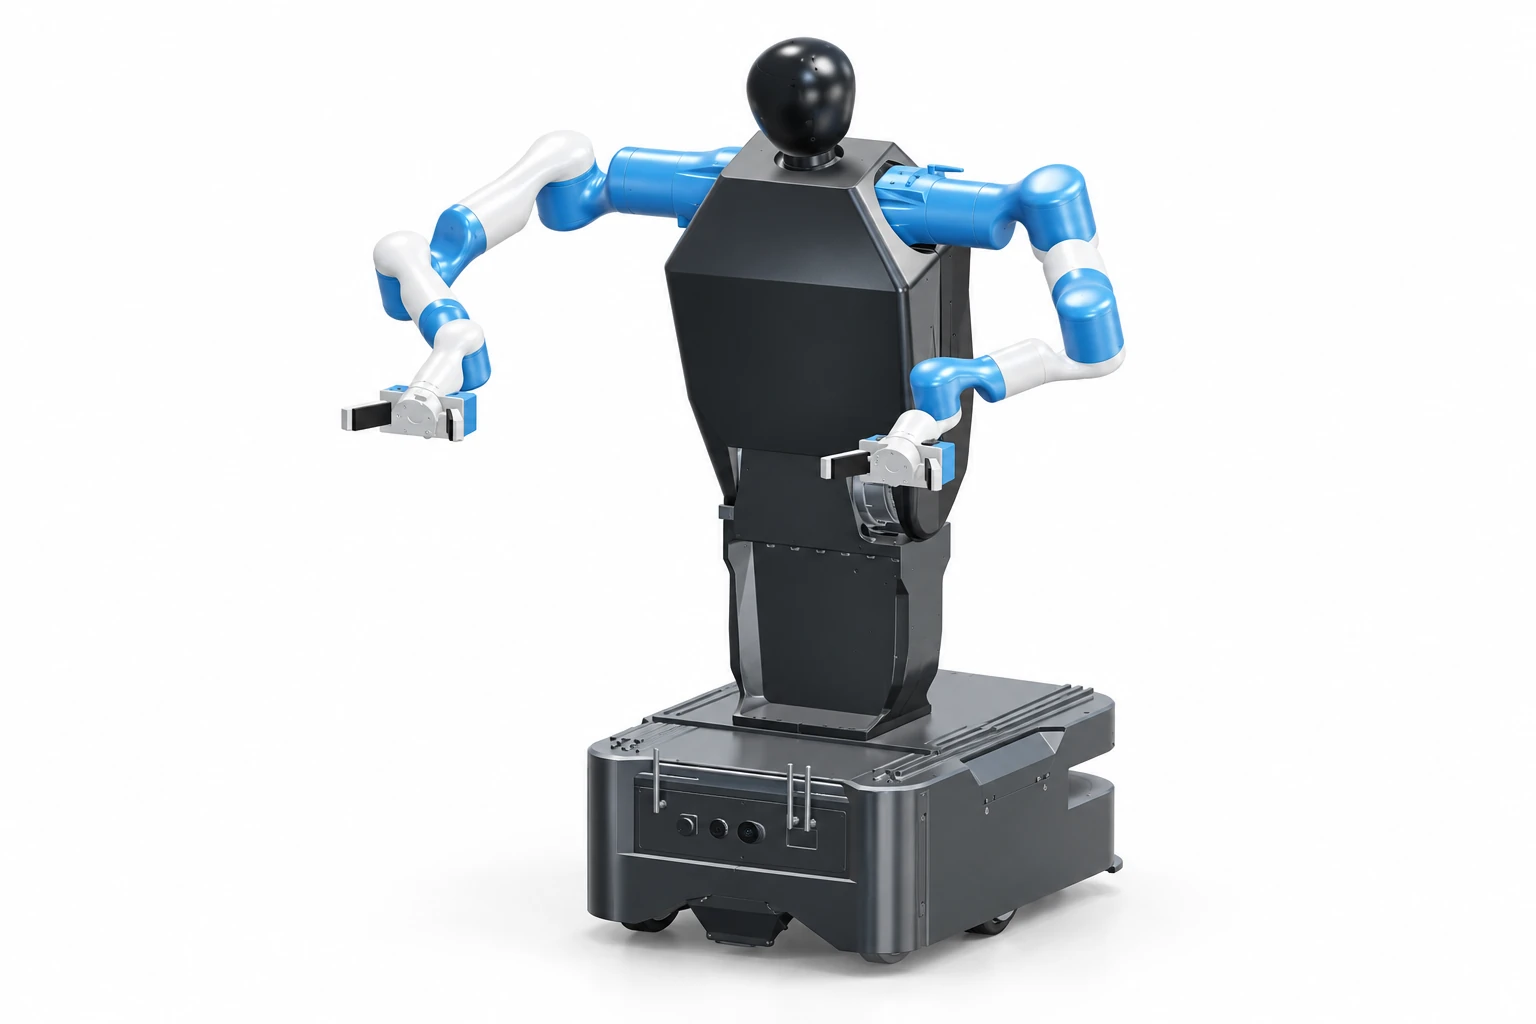
Platform overview
| Model | MDA1 |
|---|---|
| Development status | Engineering prototype in development |
| Series | Industrial |
| Platform design | Mobile base and two robotic arms |
| Development focus | Mobility, grasping and coordinated manipulation |
Move the base to the target position and align it to establish a stable starting point for dual-arm operation.
Study coordinated arm movements and object orientation during grasping, supported lifting and handovers.
Connect mobility and manipulation, with research into task transitions, state feedback and recovery after faults.
Validation status
Current materials show the robot design and simulated mobile dual-arm tasks. Dimensions, weight, speed, runtime, arm payload, workspace and accuracy have not yet been validated and are not published as product specifications.
Sensors, communications and end effectors must be assessed for the task. Configuration discussions begin with the workpieces, workspace and test conditions.
Share your workpiece dimensions, working positions, access space and task sequence so we can define tests for mobility, grasping and coordinated manipulation.
Discuss your application