
Voice interaction
Recorded demonstrations show command interaction and movement. Supported commands and task actions depend on the project configuration.
OriginMind · Industrial
W1 is a wheeled platform for navigation and inspection research, with voice interaction and task-specific mapping, localization and sensing modules.
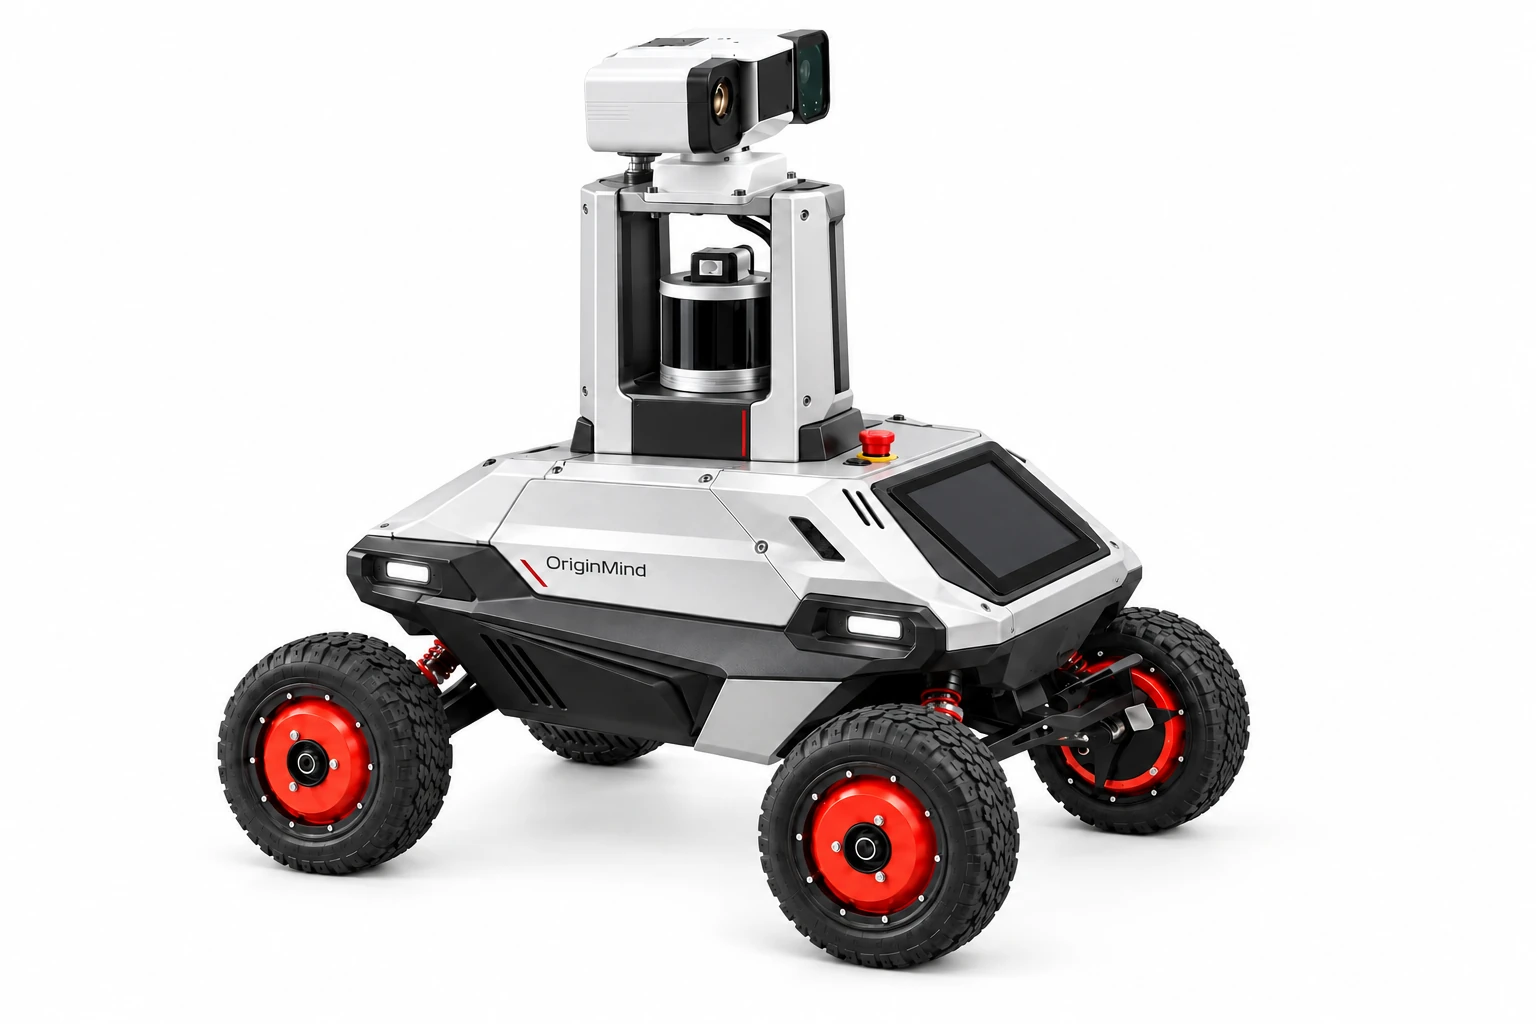
Platform overview
| Robot type | W1 wheeled inspection robot |
|---|---|
| Development status | Engineering prototype in development |
| Core software | Voice interaction |
| Optional modules | Mapping, localization, navigation and inspection |
The rendering shows an enclosure concept on a wheeled chassis for configuration assessment and application validation.
Discuss your applicationW1 supports ground-mobility research and application trials in campuses, warehouses and industrial facilities. The chassis, sensors and OmindOS integration can be assessed around inspection points and site workflows.
Recorded demonstrations show command interaction and movement. Supported commands and task actions depend on the project configuration.
Mapping, localization and navigation are optional modules. The inspection demonstration shows robot movement alongside map building and a first-person view.
Visible-light cameras, thermal imaging and other sensors can be assessed for the task. The inspection demonstration shows multiple image feeds and waypoint tasks.
Technical details
| Dimensions | 730 × 460 × 860 mm |
|---|---|
| Battery runtime | > 4 h |
| Turning capability | In-place rotation |
| Maximum speed | 1.5 m/s |
| Payload | 10 kg |
These are reference specifications for the wheeled inspection platform. Confirm the hardware configuration and test conditions with us before using these values for project planning. The hardware, sensors and software supplied are defined in the agreed order.
Inspection plans depend on the route, available space and inspection targets. Sensors are selected for the task.
Follow designated routes, capture images at selected locations and record site conditions.
Assess visible-light cameras, thermal imaging and environmental sensors against viewing distance, temperature range and lighting.
Define OmindOS integration around site maps, task commands and data requirements.
Thermal imaging shows temperature distribution on an object's surface. The videos show different laboratory and field configurations; inspection modules, software functions and task scope depend on the project.