
Tracked-platform adaptation
Develop the robot layout and enclosure around a tracked chassis, checking clearances, turning space and ground conditions along the intended route.
OriginMind · Industrial · In development
T1 is a tracked inspection robot in development for mining. Research focuses on adapting a tracked platform to site conditions and integrating environmental sensing, with an enclosure designed around a tracked chassis.
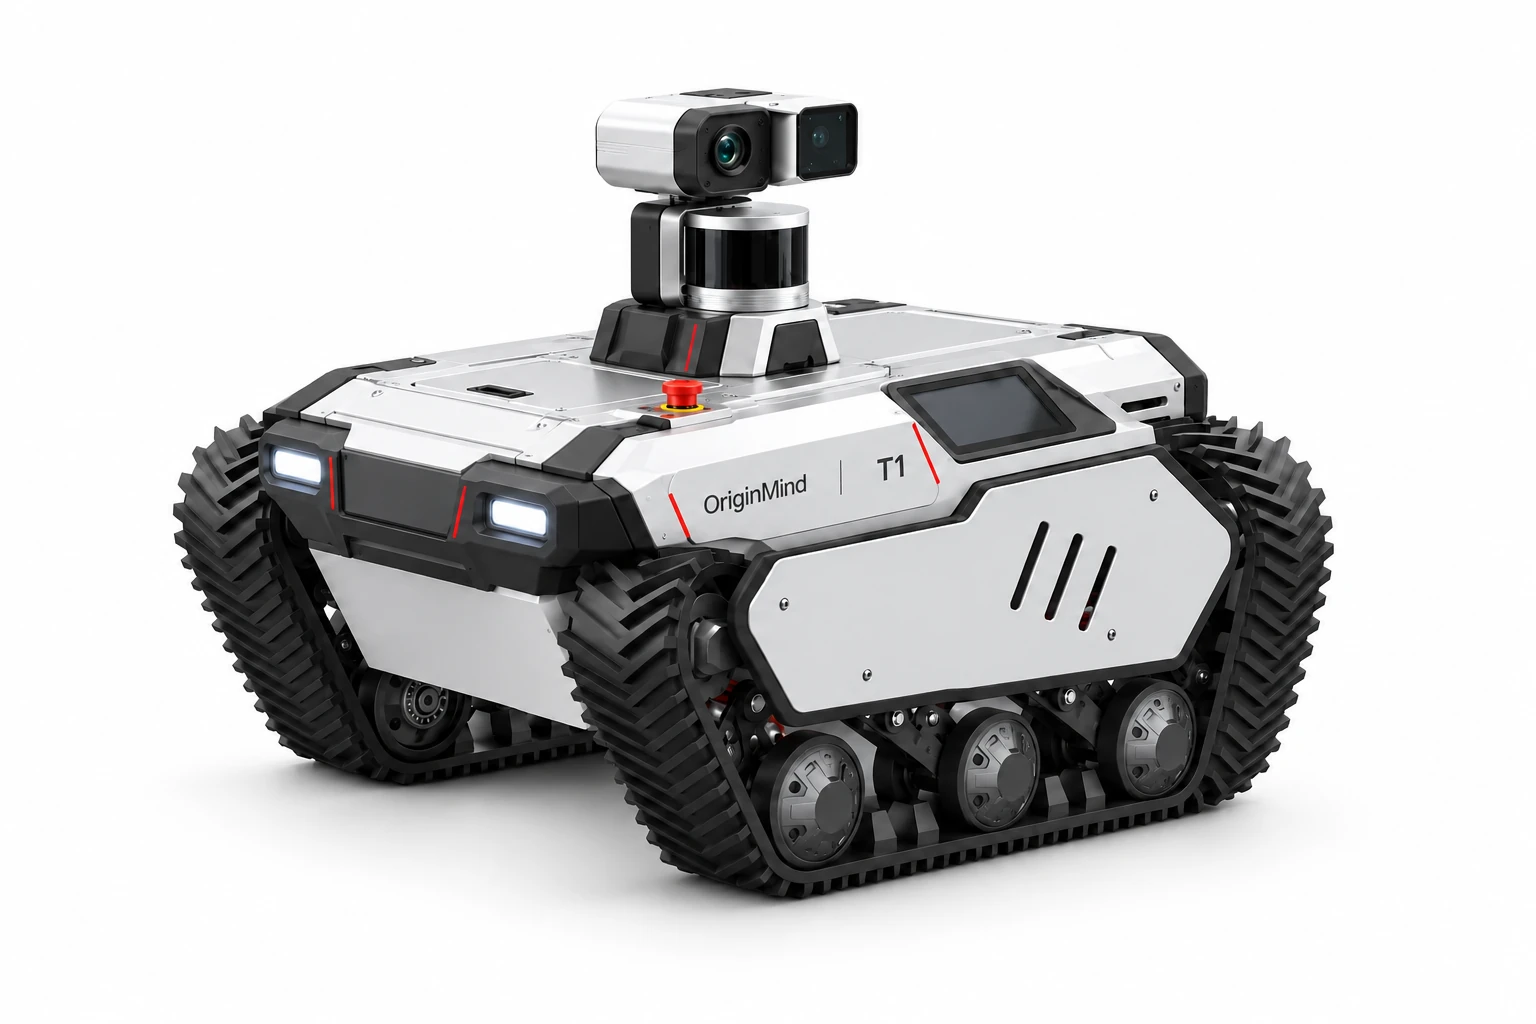
Platform overview
| Robot type | T1 tracked inspection robot |
|---|---|
| Development status | In development; rendering shows the enclosure concept |
| Chassis | Tracked chassis |
| Research focus | Site adaptation, environmental sensing and inspection tasks |
The rendering illustrates the current enclosure concept. Whole-robot configuration, terrain capability and software integration require validation against the prototype and site conditions.
Discuss your applicationResearch assesses tracked-platform requirements around mine passages, equipment layouts and observation points.
Develop the robot layout and enclosure around a tracked chassis, checking clearances, turning space and ground conditions along the intended route.
Assess cameras, LiDAR and other sensors against inspection targets, including sensor placement and retention of observation records.
Connect movement, observation and record keeping with maps, inspection points and task feedback, while validating OmindOS integration.
Mining fieldwork · Earlier research
The team has conducted research in underground metal mines, including driving and environmental data capture with an earlier tracked platform. These field records inform T1 requirements and future validation.
The videos show an earlier research platform whose appearance and configuration differ from the current T1 enclosure concept. They do not establish T1 performance or certification.
Explore mining field recordsStart with a single route and inspection point. Confirm the robot configuration, software version and evaluation method before expanding the test scope.
Check passage dimensions, slopes, obstacles, lighting and communications coverage. Define operator intervention and fault-handling procedures.
Select sensors and onboard computing for the task, then confirm control interfaces and the scope of OmindOS integration and testing.
Link routes, inspection points, original imagery and operator interventions. Assess suitability using the specific configuration and recorded test results.
The published field records come from underground metal-mine research. Applications in potentially explosive atmospheres require separate review of the exact model, certification documentation and site access requirements.