
In development
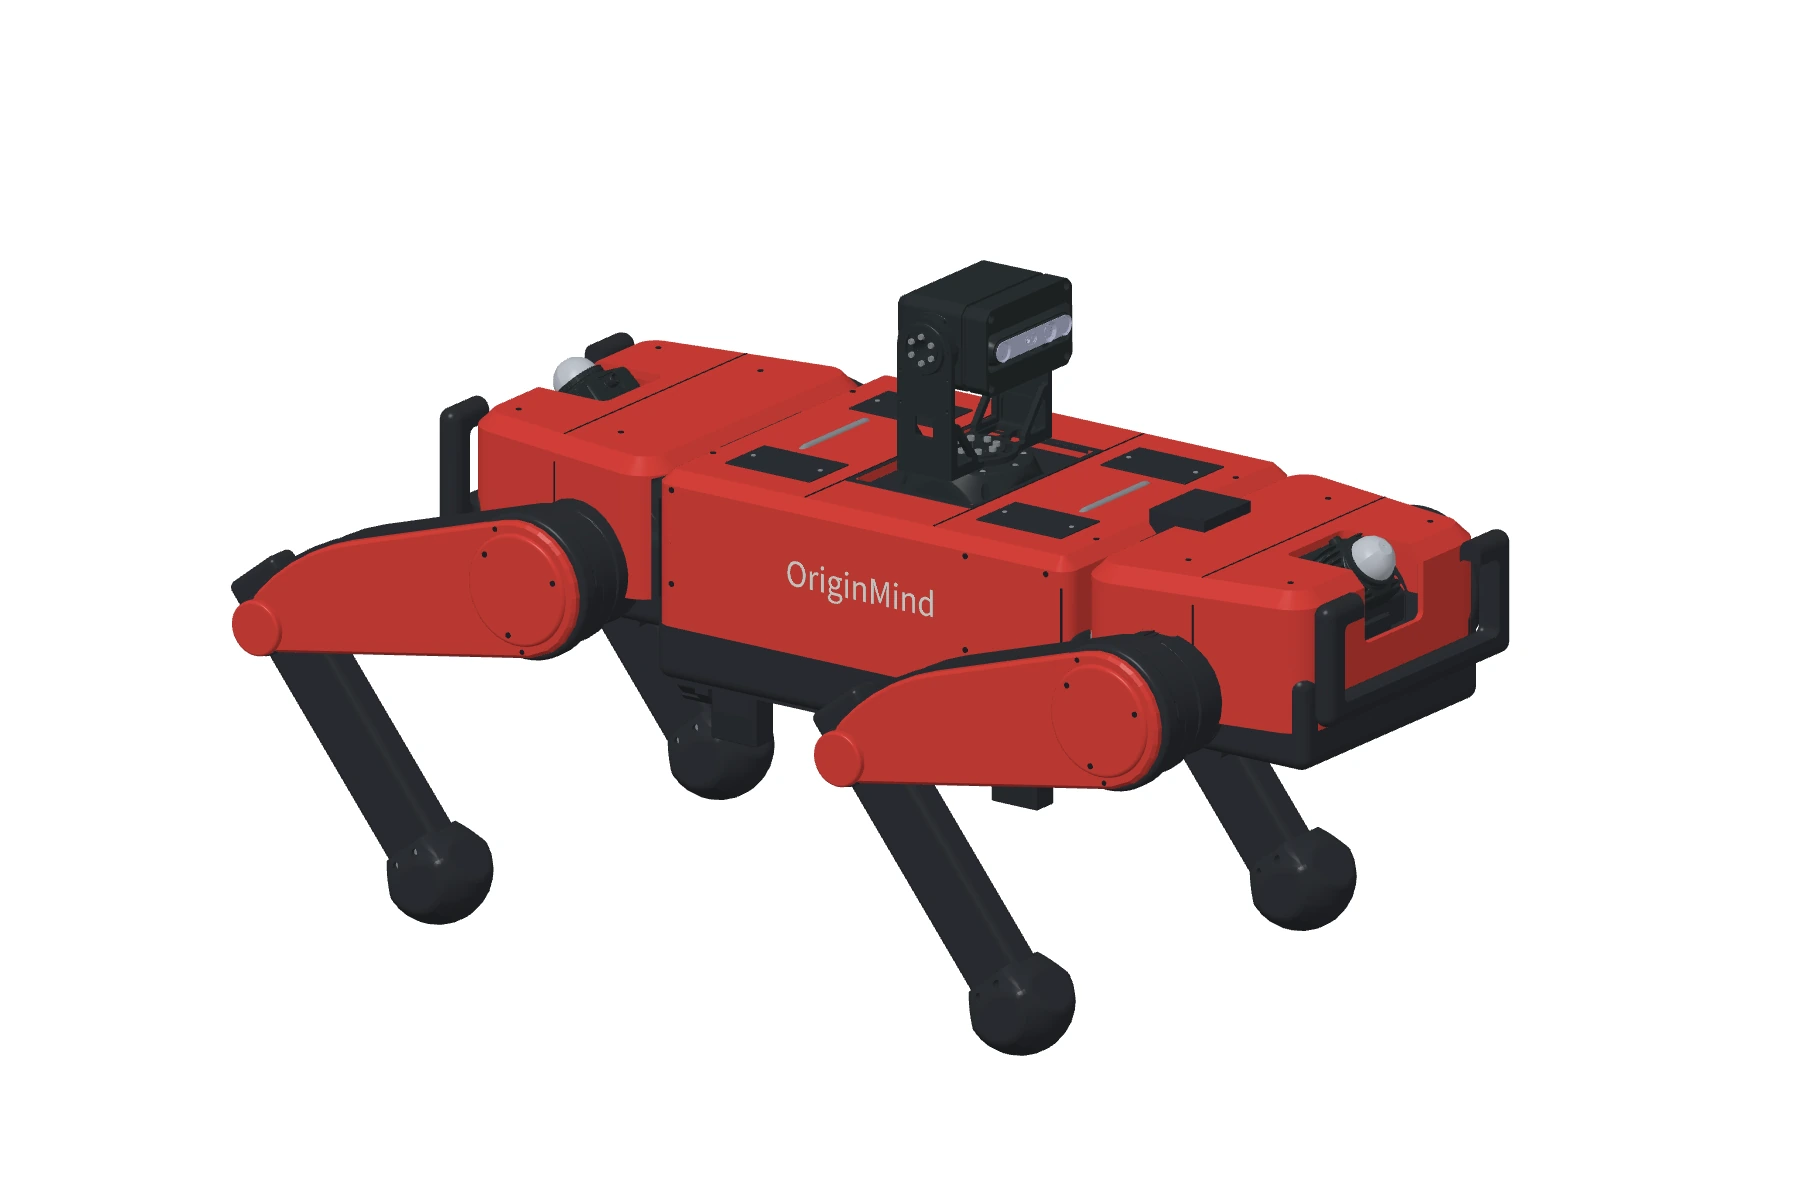
Q1 Quadruped inspection robot
In development for navigation through mine passages and equipment inspection, with research into mobility, perception and task execution.
Q1 design concept
Robots and platforms
Our core development focus is quadruped inspection for mining, alongside tracked, wheeled, dual-arm and research platforms. Explore each model for its development status, reference configuration and demonstrations.
Explore Q1OriginMind
Quadruped, tracked and wheeled inspection platforms, plus mobile dual-arm manipulation.
In development
In development for navigation through mine passages and equipment inspection, with research into mobility, perception and task execution.
Q1 design concept
In development
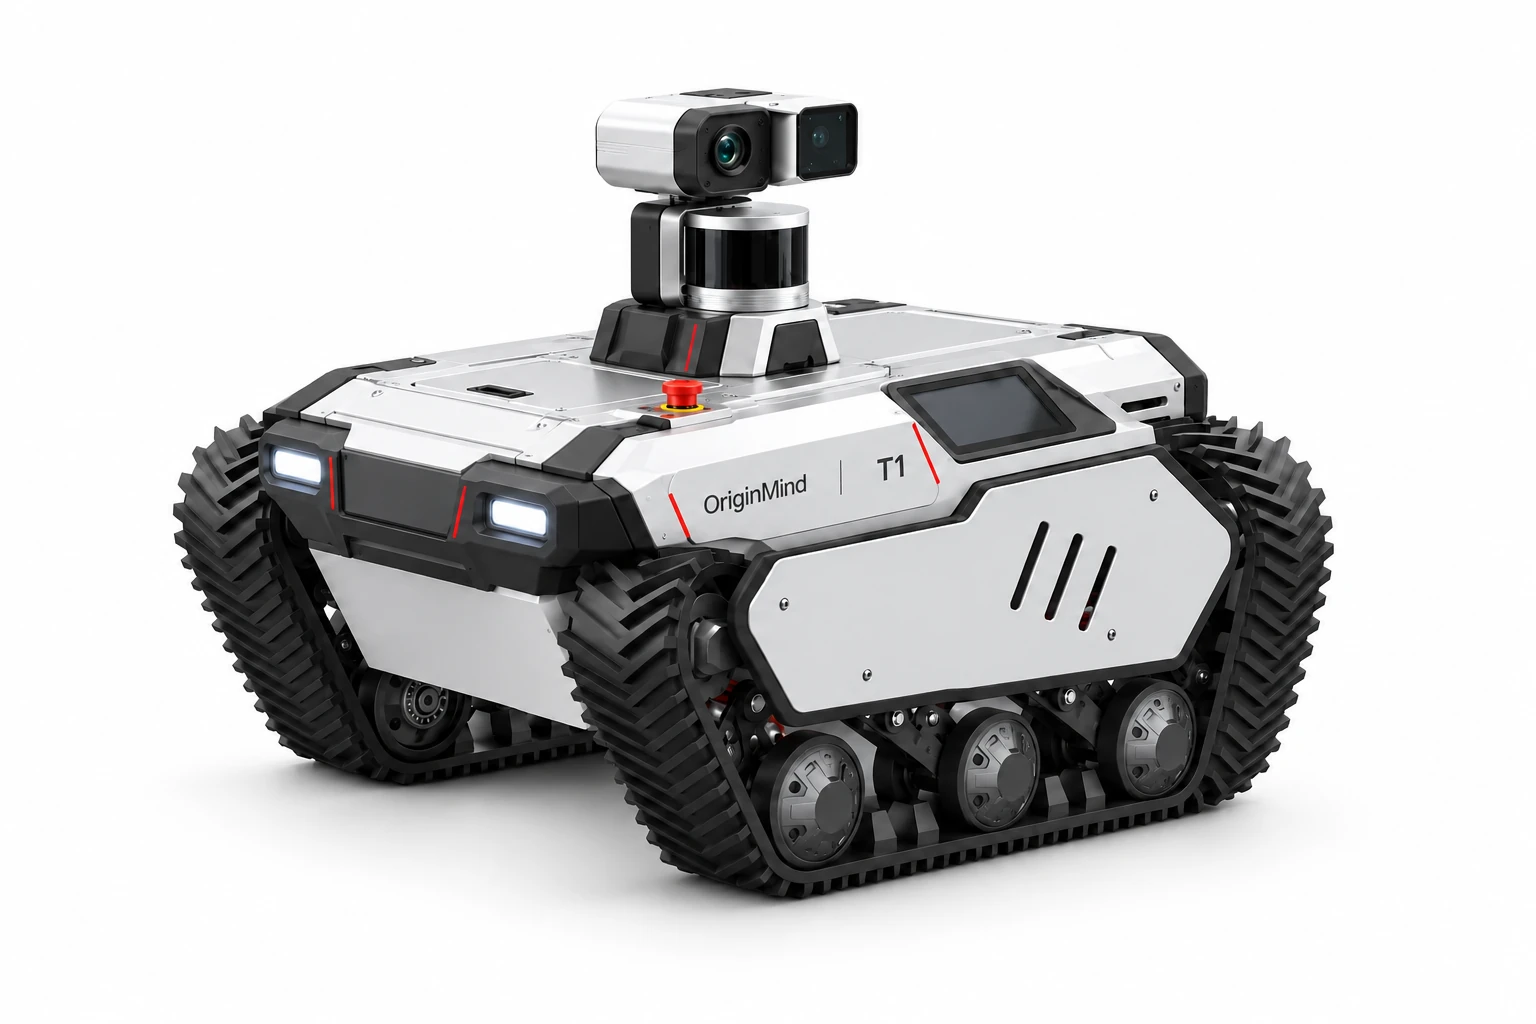
An inspection robot in development for mining, with a purpose-designed enclosure on a tracked chassis.
Enclosure concept · Tracked chassis
In development
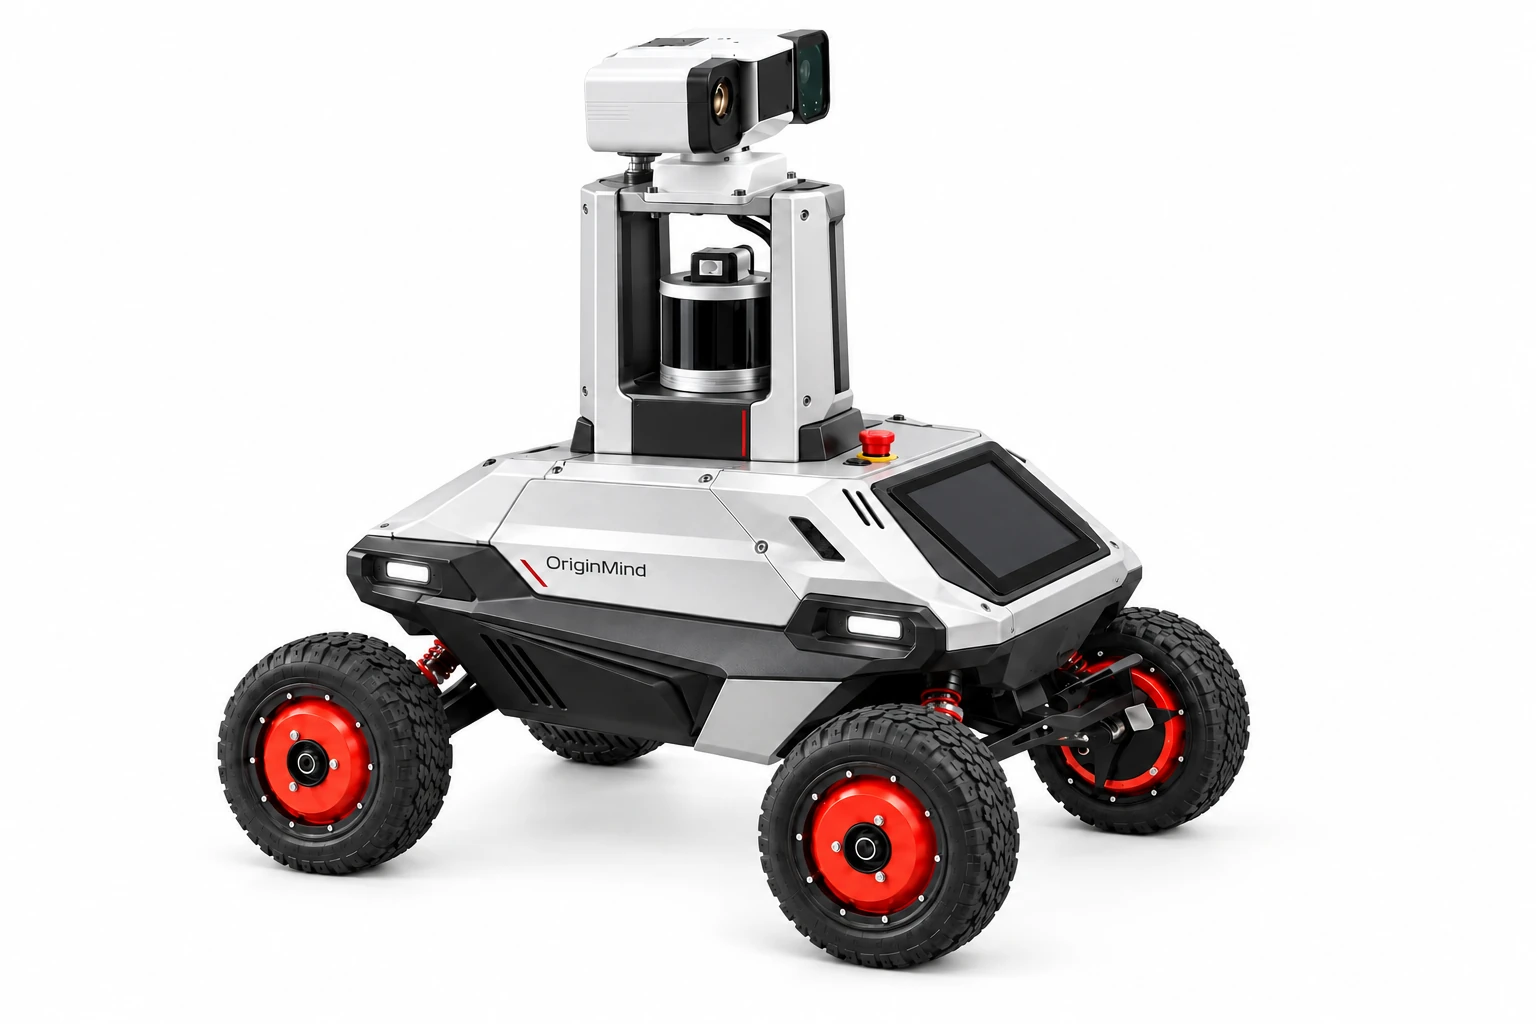
A wheeled platform with voice interaction and optional mapping, localization, navigation and inspection modules.
Enclosure concept
In development
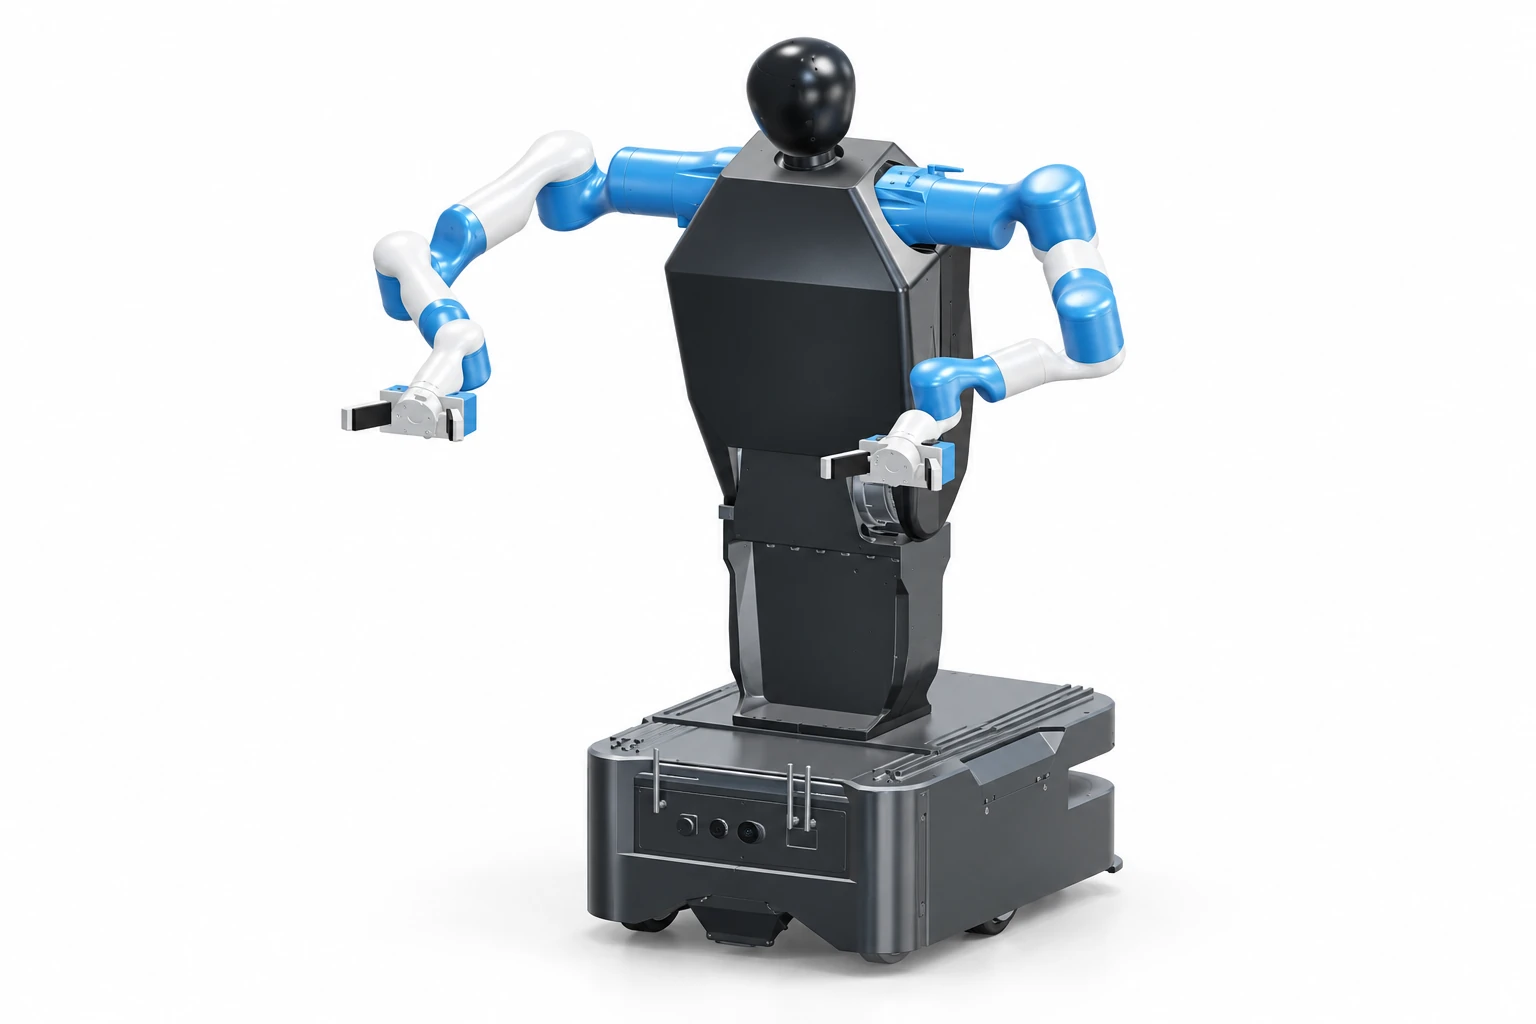
A mobile base with two robotic arms for research into mobile grasping and coordinated manipulation.
Mechanical designs, experimental demonstrations and robotics courses.
Explore robotics courses (Chinese)
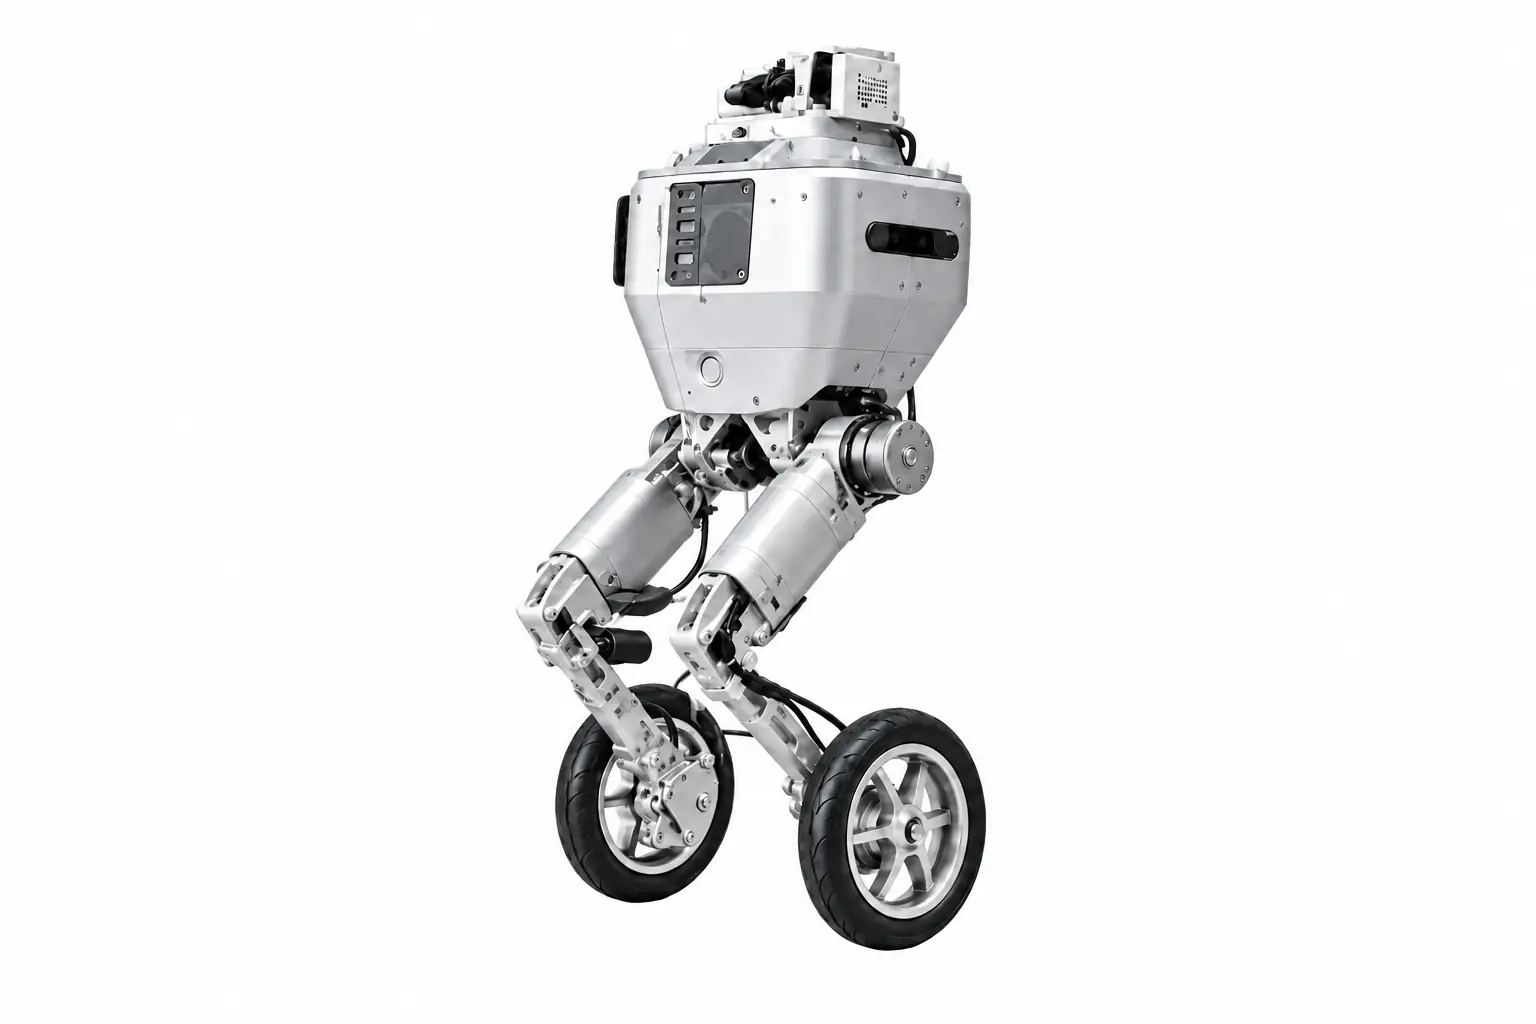
Prototype
An enclosed platform for experiments in wheel-and-leg coordination and hardware integration.
Design rendering
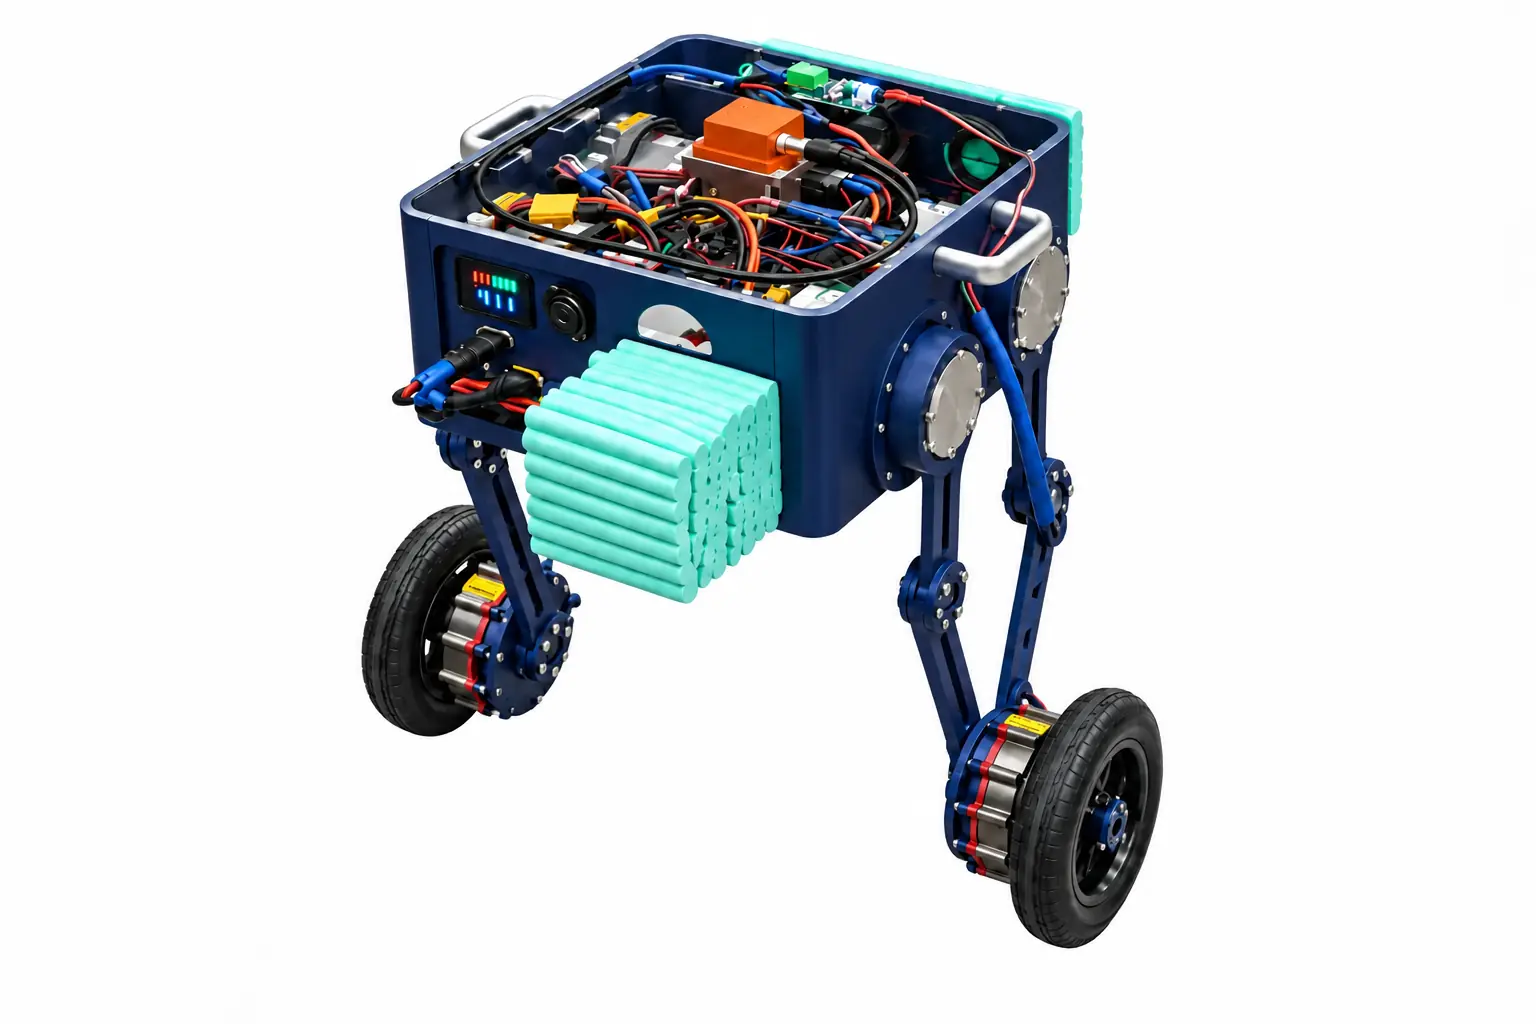
Prototype
Parallel-linkage legs and an open frame provide access for wiring, equipment installation and motion-control experiments.
Design rendering
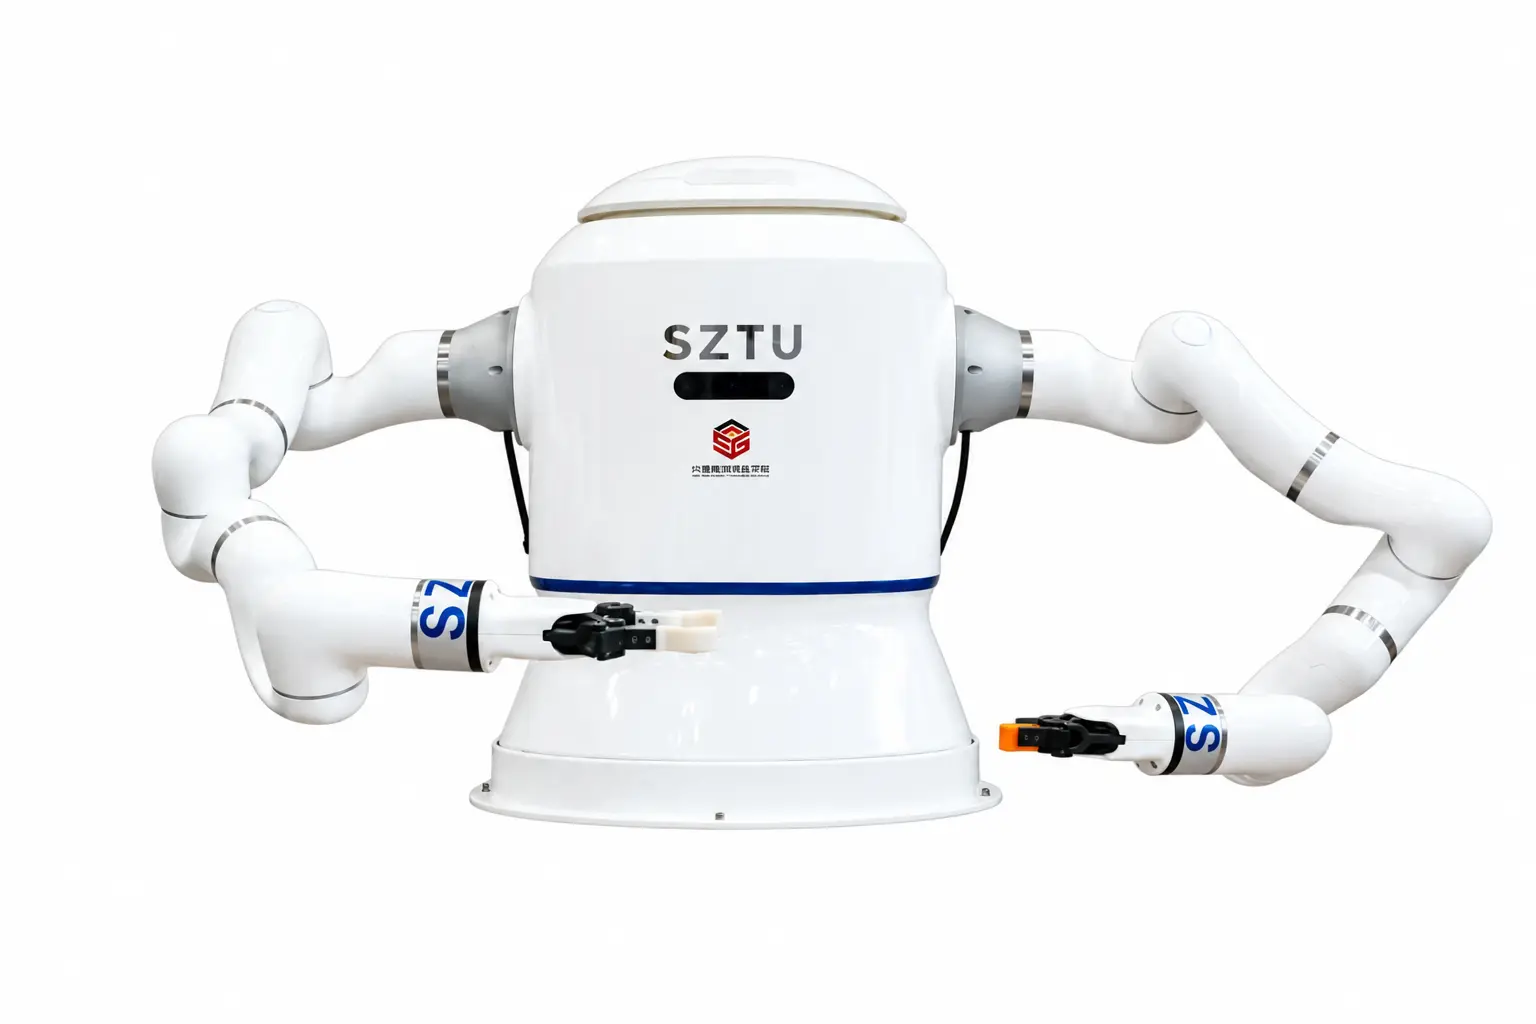
Prototype
A platform for experiments in vision-guided grasping, arm coordination, motion planning and digital twins.
Reference prototype
Compare platform designs, intended applications and development status, then explore the configuration and validation scope for each model.
| Comparison | Q1 Quadruped inspection | T1 Tracked inspection | W1 Wheeled inspection | MDA1 Mobile dual-arm |
|---|---|---|---|---|
| Status | In development | In development | In development | In development |
| Platform design | Quadruped robot | Tracked chassis | Wheeled chassis | Mobile base and two robotic arms |
| Intended applications | Mine access and equipment inspection | Mine inspection | Navigation, voice interaction and inspection | Mobility, grasping and arm coordination |
| Discuss with us | Terrain, routes and inspection targets | Route access and enclosure integration | Ground conditions, payload and sensors | Workpieces, workspace and task sequences |
| Details and demonstrations | Explore Q1 | Explore T1 | Explore W1 | Explore MDA1 |
Scroll horizontally on smaller screens. Refer to each product page for reference specifications and validation scope.
Tell us about your operating environment, payload, equipment interfaces and target tasks. For teaching and research, include your experimental objectives and course requirements so we can discuss a suitable platform and configuration.
Discuss your requirements