
Q1
Quadruped inspection robot
A four-legged platform being developed for mine inspection, combining cameras, LiDAR and inertial sensing with research in autonomous navigation.
Explore Q1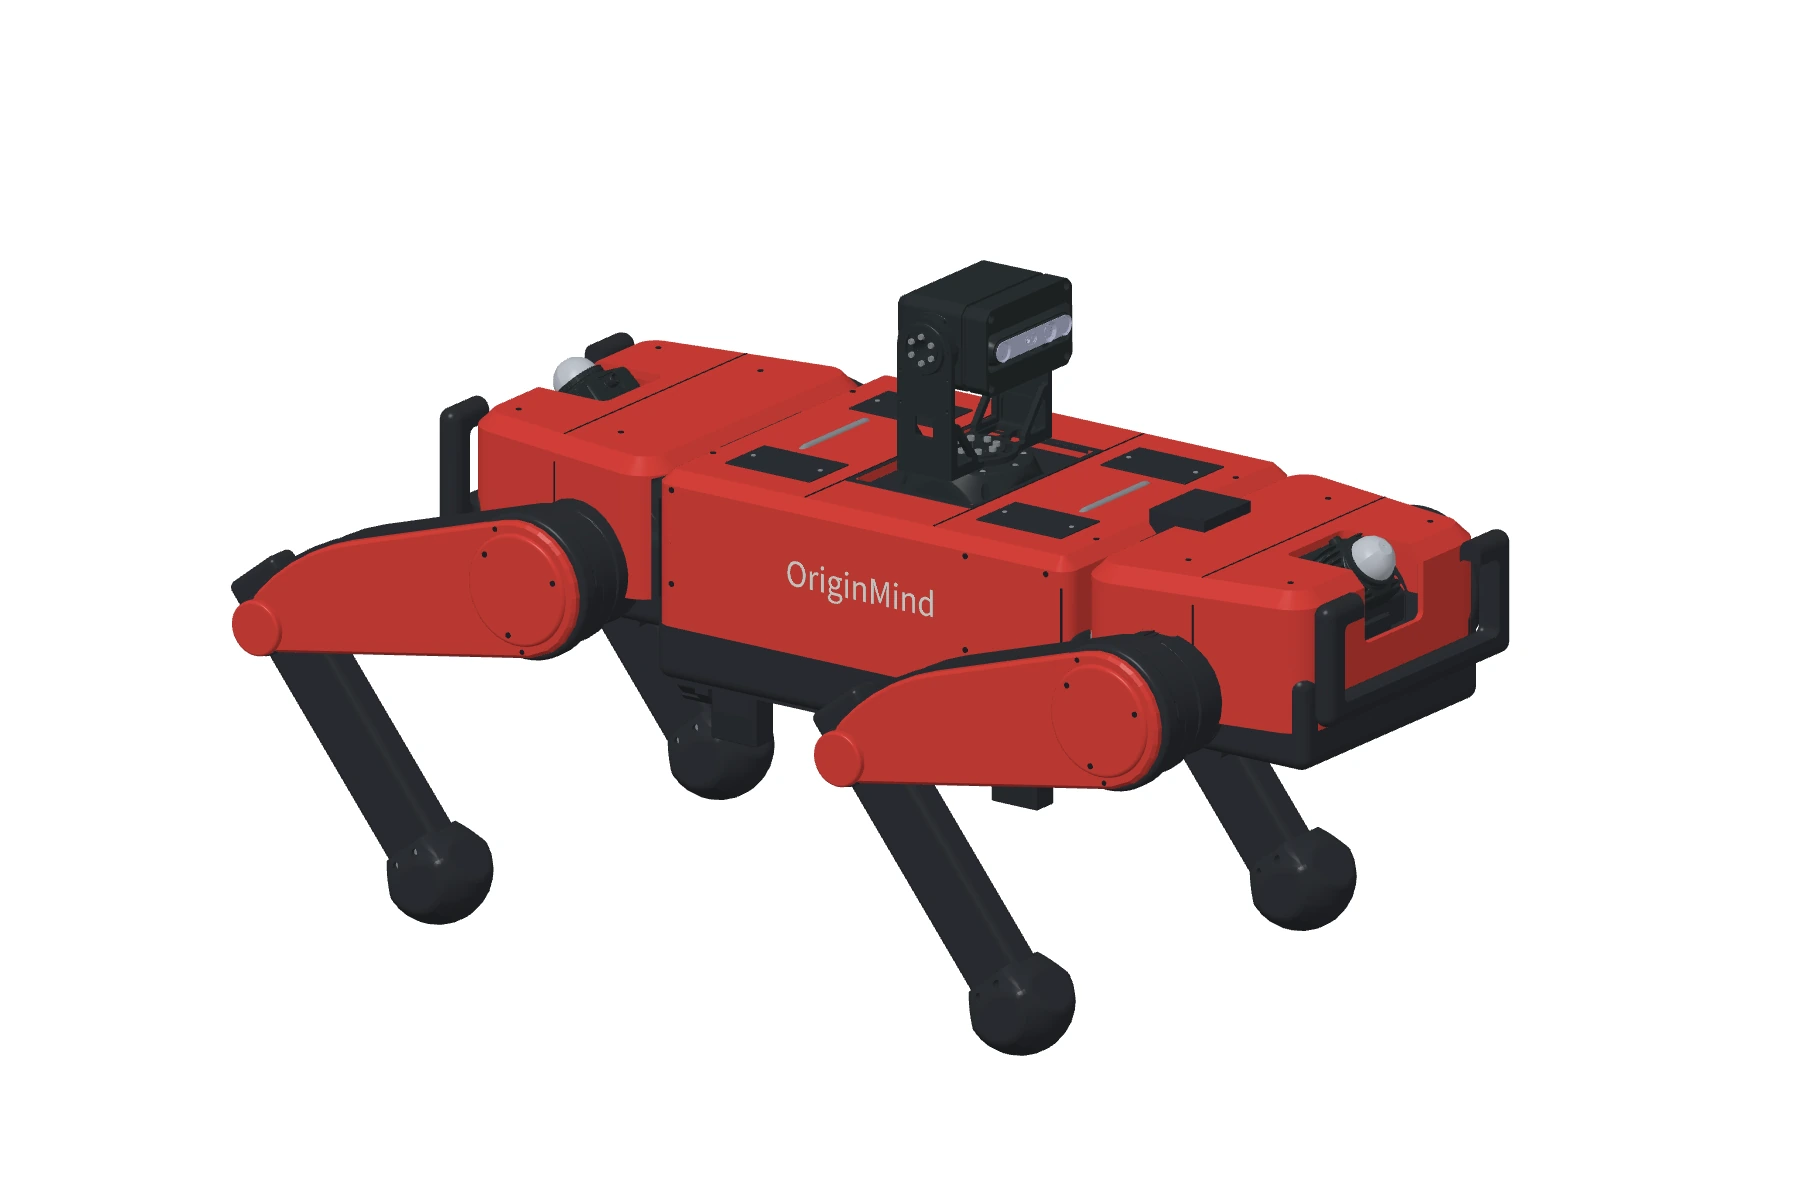
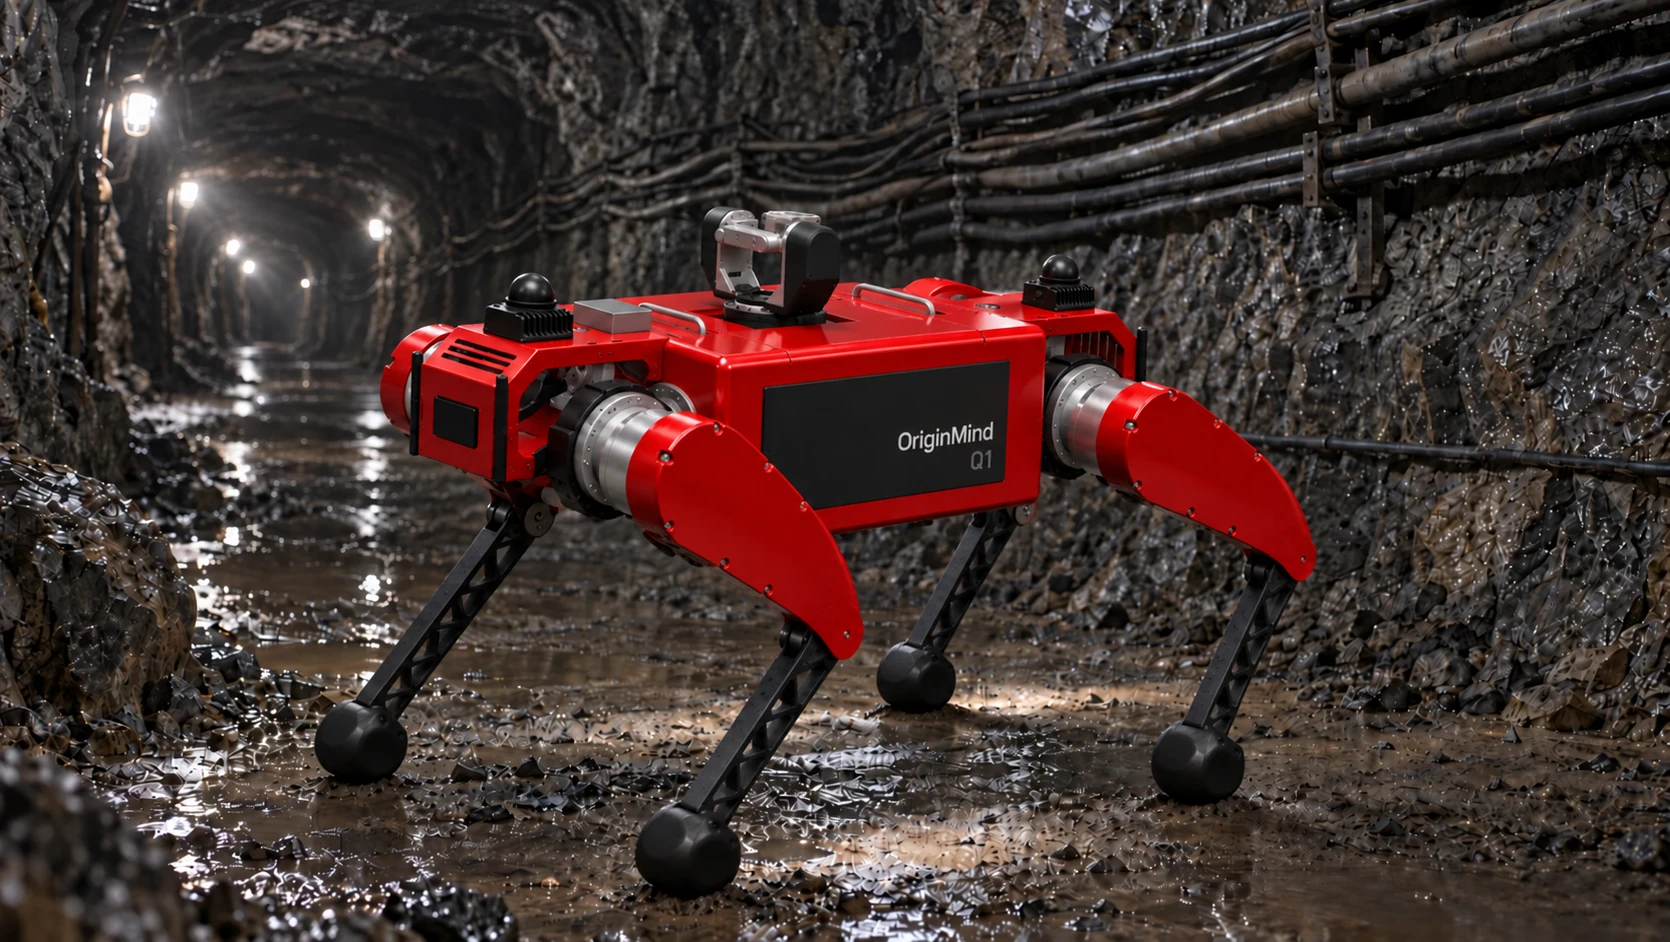
Q1 inspection · Task-level software
Q1 concept · In development
01 Robot platforms
A four-legged platform being developed for mine inspection, combining cameras, LiDAR and inertial sensing with research in autonomous navigation.
Explore Q1Built around a general-purpose tracked chassis, T1 explores terrain adaptation and environmental sensing for mine inspection.
Explore T1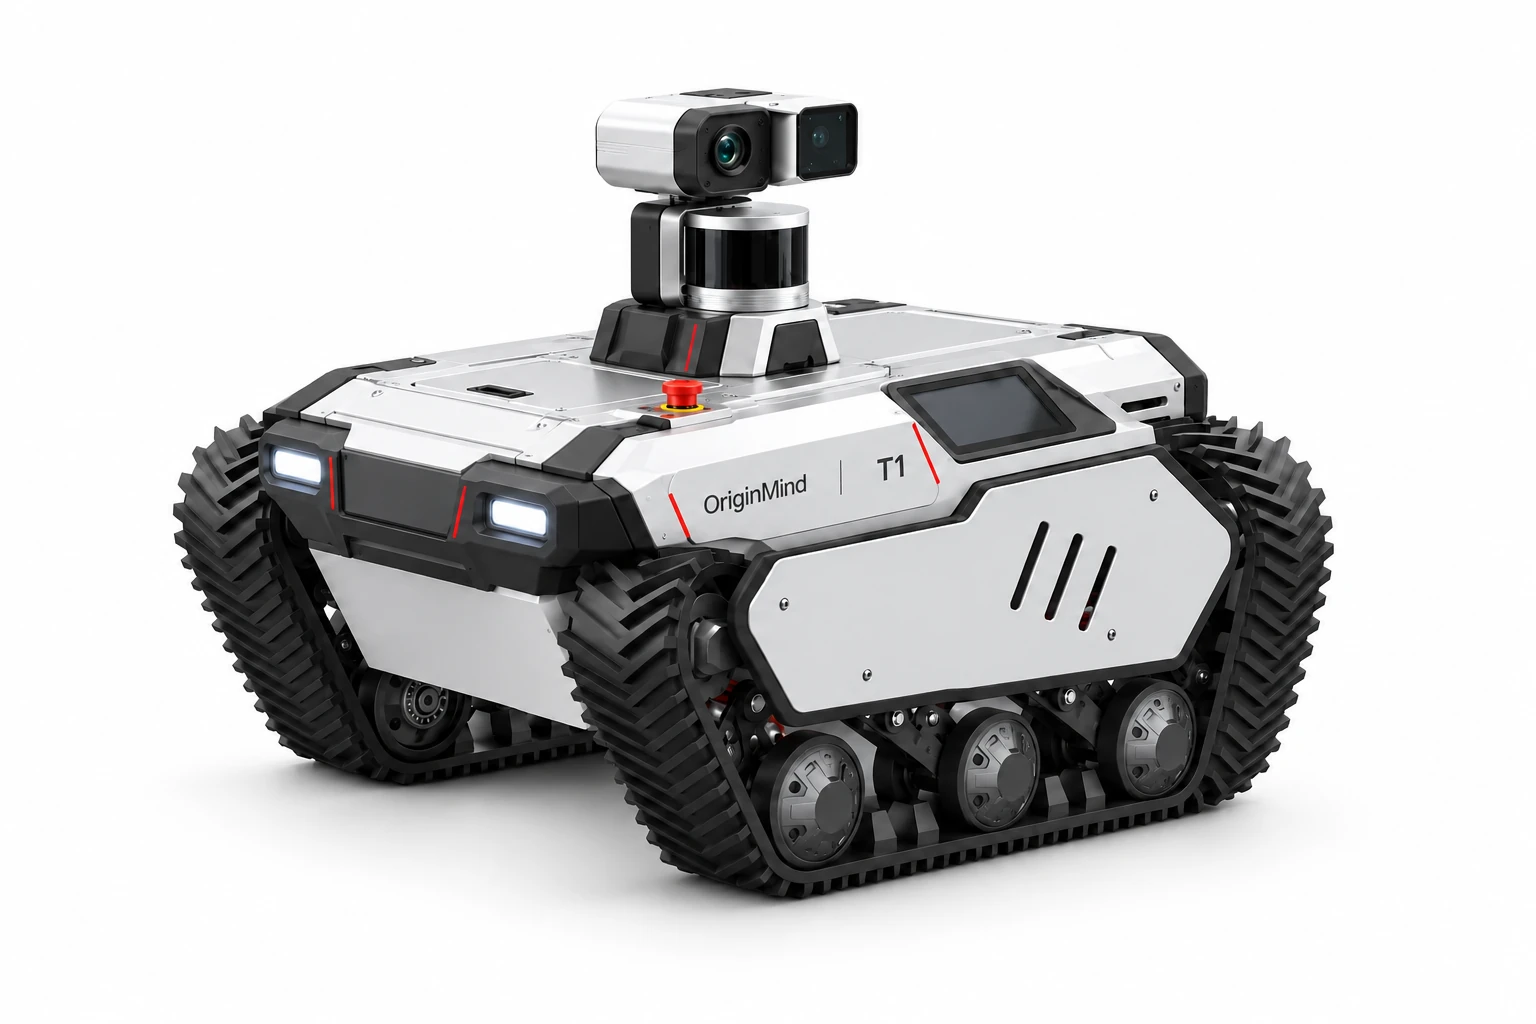
A wheeled platform being developed for autonomous navigation and environmental sensing, with site conditions guiding the configuration.
Explore W1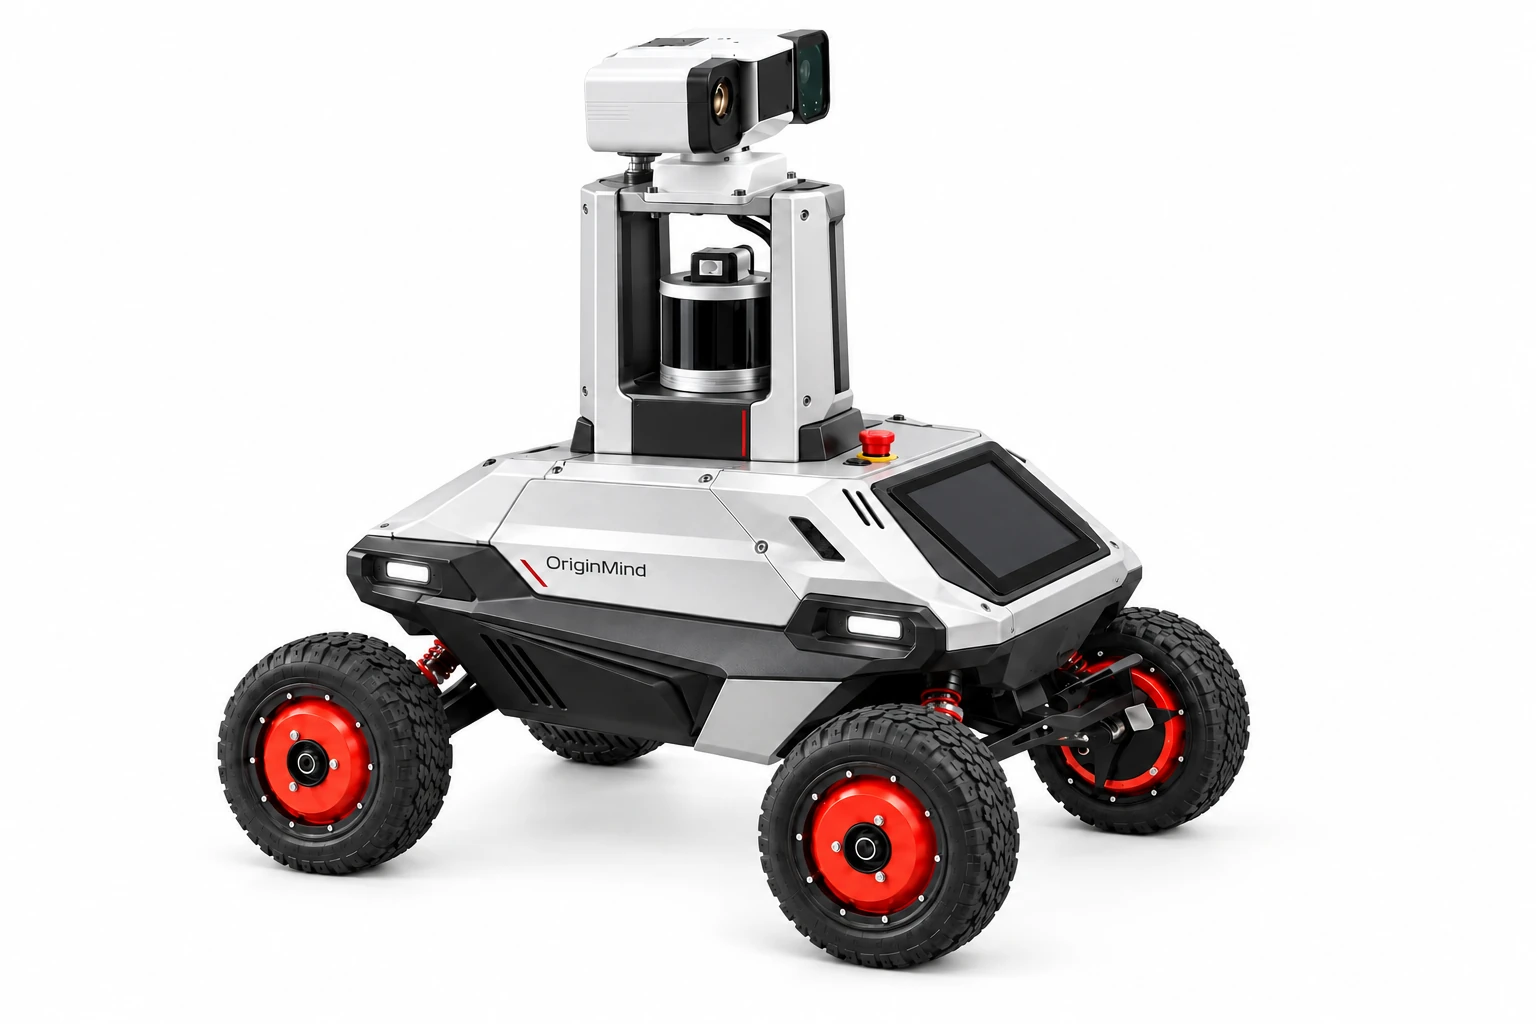
A mobile dual-arm platform under development for coordinated navigation, grasping and manipulation.
Explore MDA1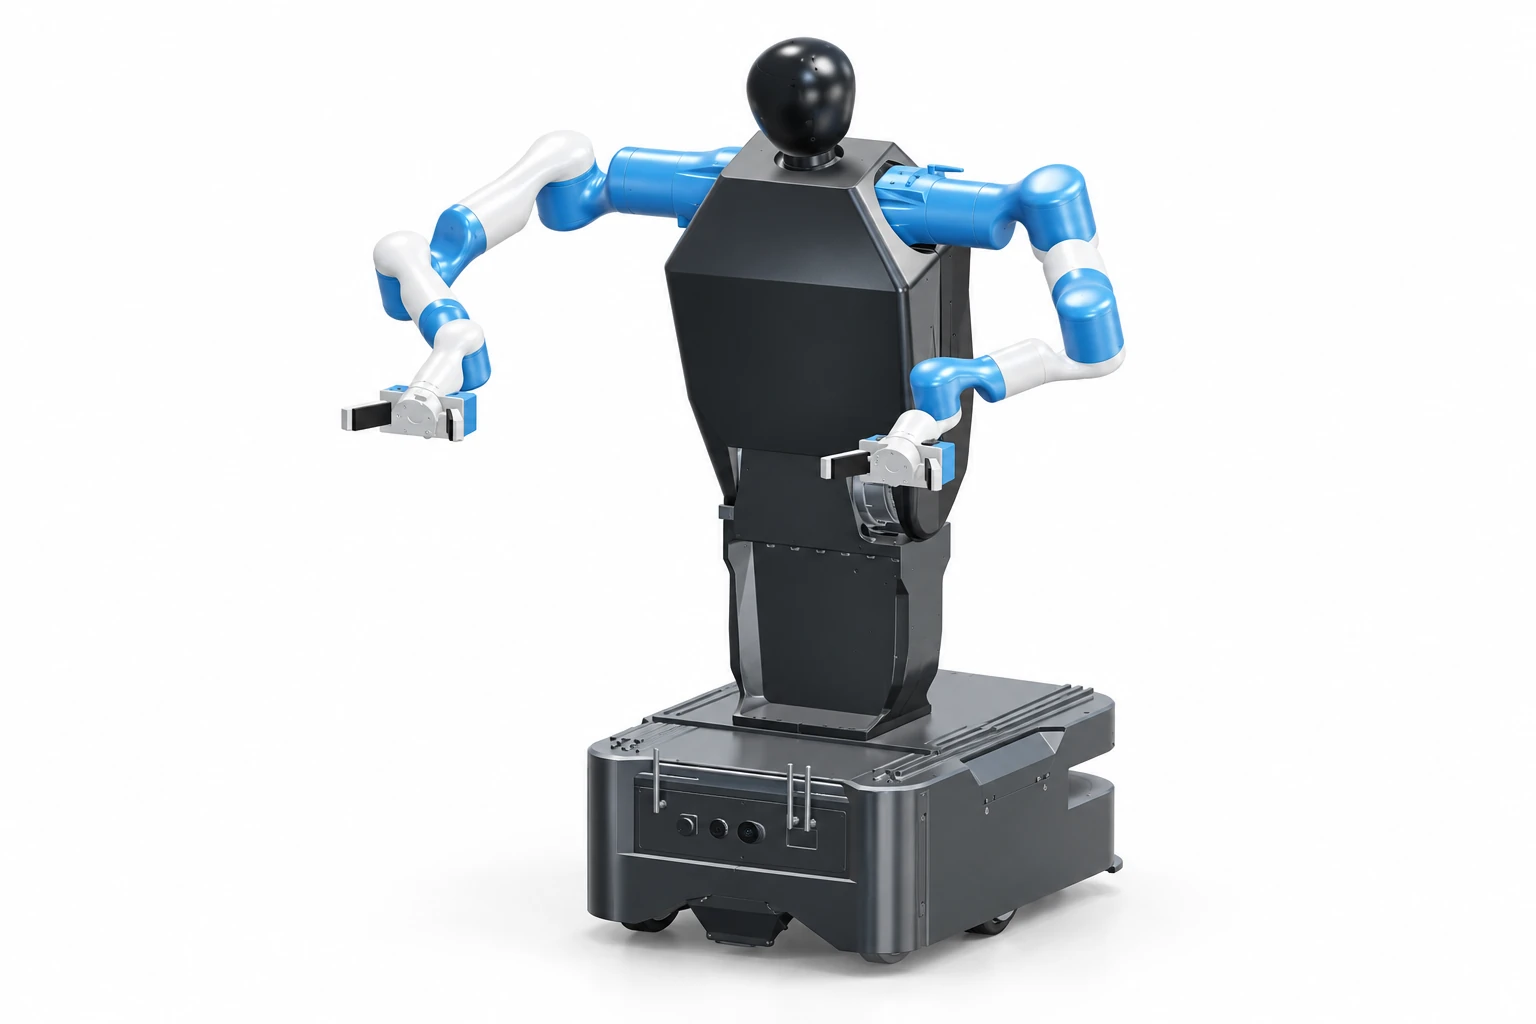
Platform selection
These are development and configuration directions. Suitability depends on whole-robot testing, site conditions and access requirements.
Research into mobility over uneven mine passages and obstacles.
Assess slopes, obstacles, power and task payload.Site adaptation and inspection integration on a tracked platform.
Assess ground traction, passage widths and turning space.Fixed routes and inspection points in relatively level areas.
Assess surface continuity, routes and observation points.Grasping and coordinated manipulation after base positioning.
Assess workpieces, end effectors and safe working space.02 Software · OmindOS
Connect navigation, manipulation and digital twins. Explore the system in OmindOS Cloud and plan the integration for your platform.
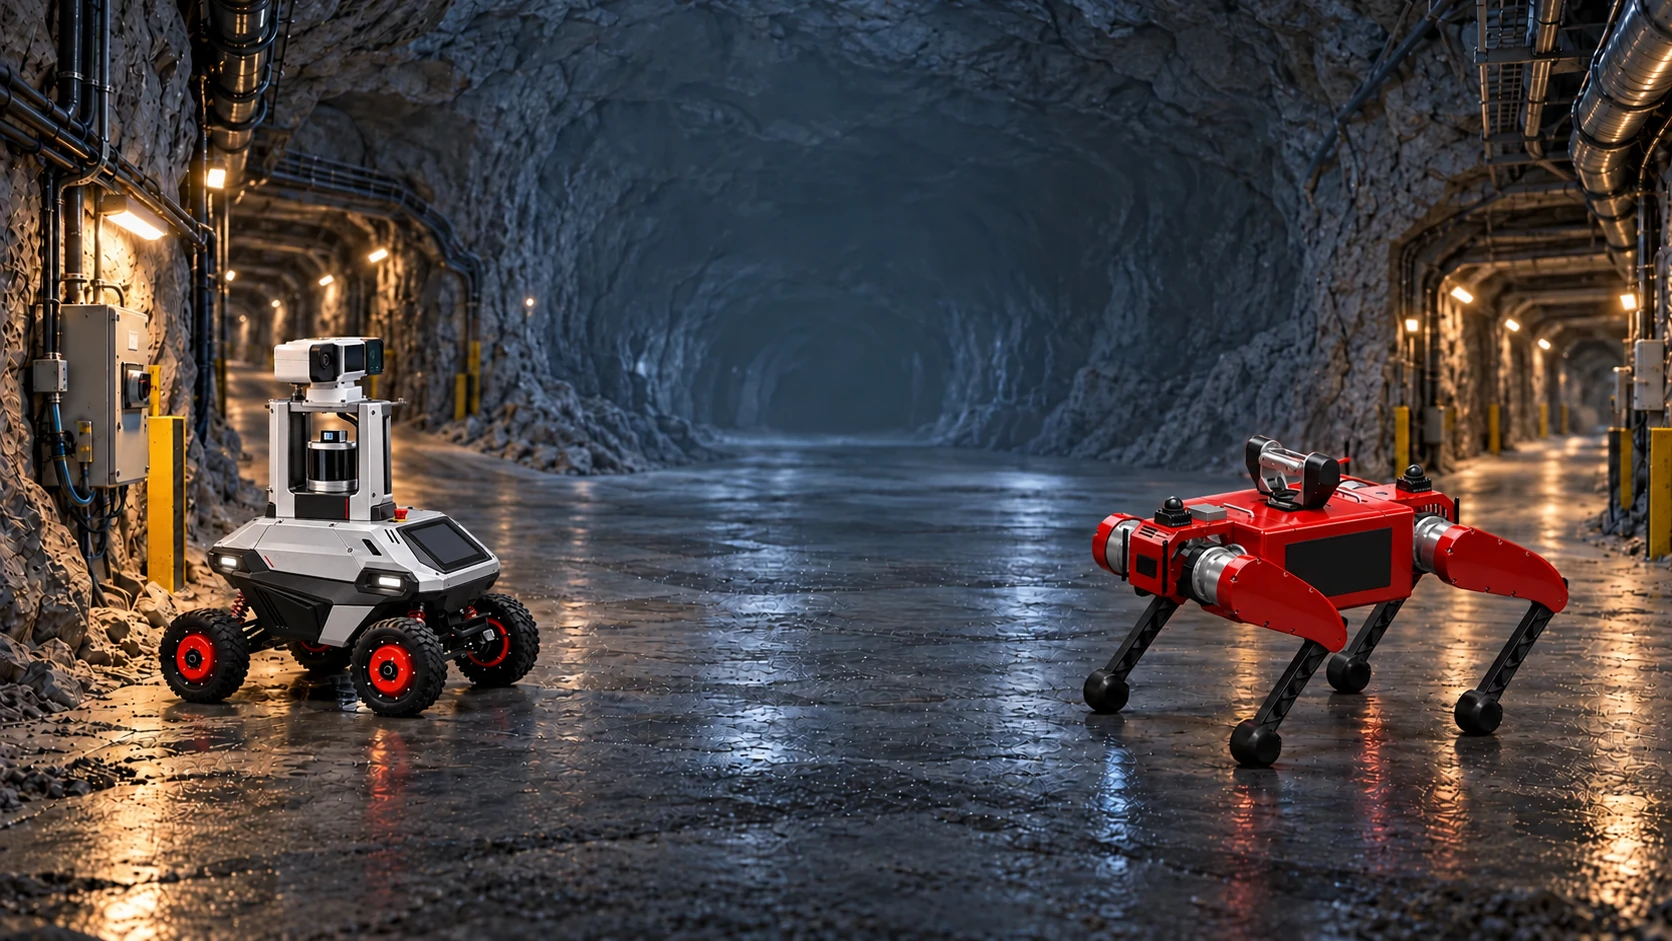
Organize environment maps, robot locations and inspection points.
Connect routes and actions in a defined task sequence.
Review robot status, task progress and execution records.
Adapt hardware and software, then validate the deployment.
03 About OriginMind
Field experience and laboratory research guide how we develop robots.
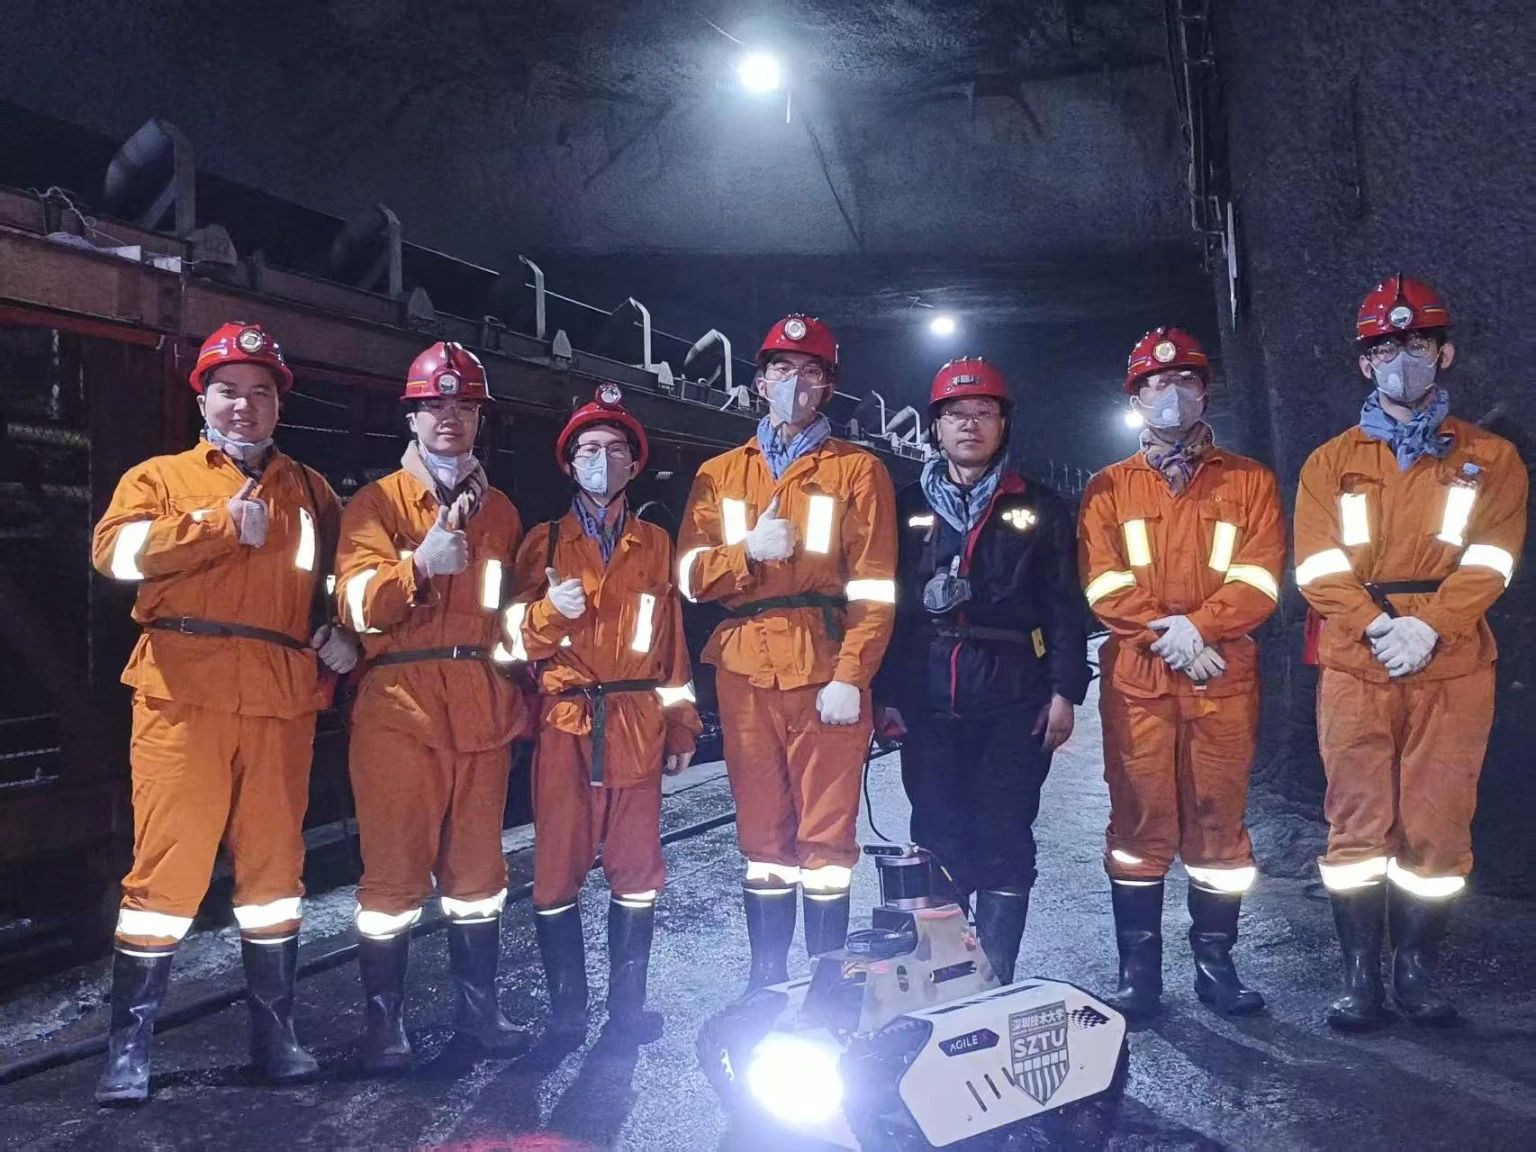
OriginMind works with ARTS Robotics at Shenzhen Technology University on autonomous navigation, manipulation and embodied intelligence.
The research spans multisensor mapping and localization, motion control, tactile sensing, planning and dual-arm coordination. Algorithms are evaluated through robot experiments and system integration.
The team’s mining inspection robot system received First Prize in the AI+ application track of the 19th Challenge Cup National College Student Academic and Technological Works Competition.
Field records
These recordings show earlier platforms and underground data capture that inform our development. Current Q1 demonstrations show its design and simulated motion.
Review the software, integration scope and field records for this platform.