Routes and terrain
Provide representative routes, passage dimensions, slopes, steps and ground photographs.
APPLICATIONS
Robot development and staged testing for mobility, localization and equipment inspection in complex underground passages.
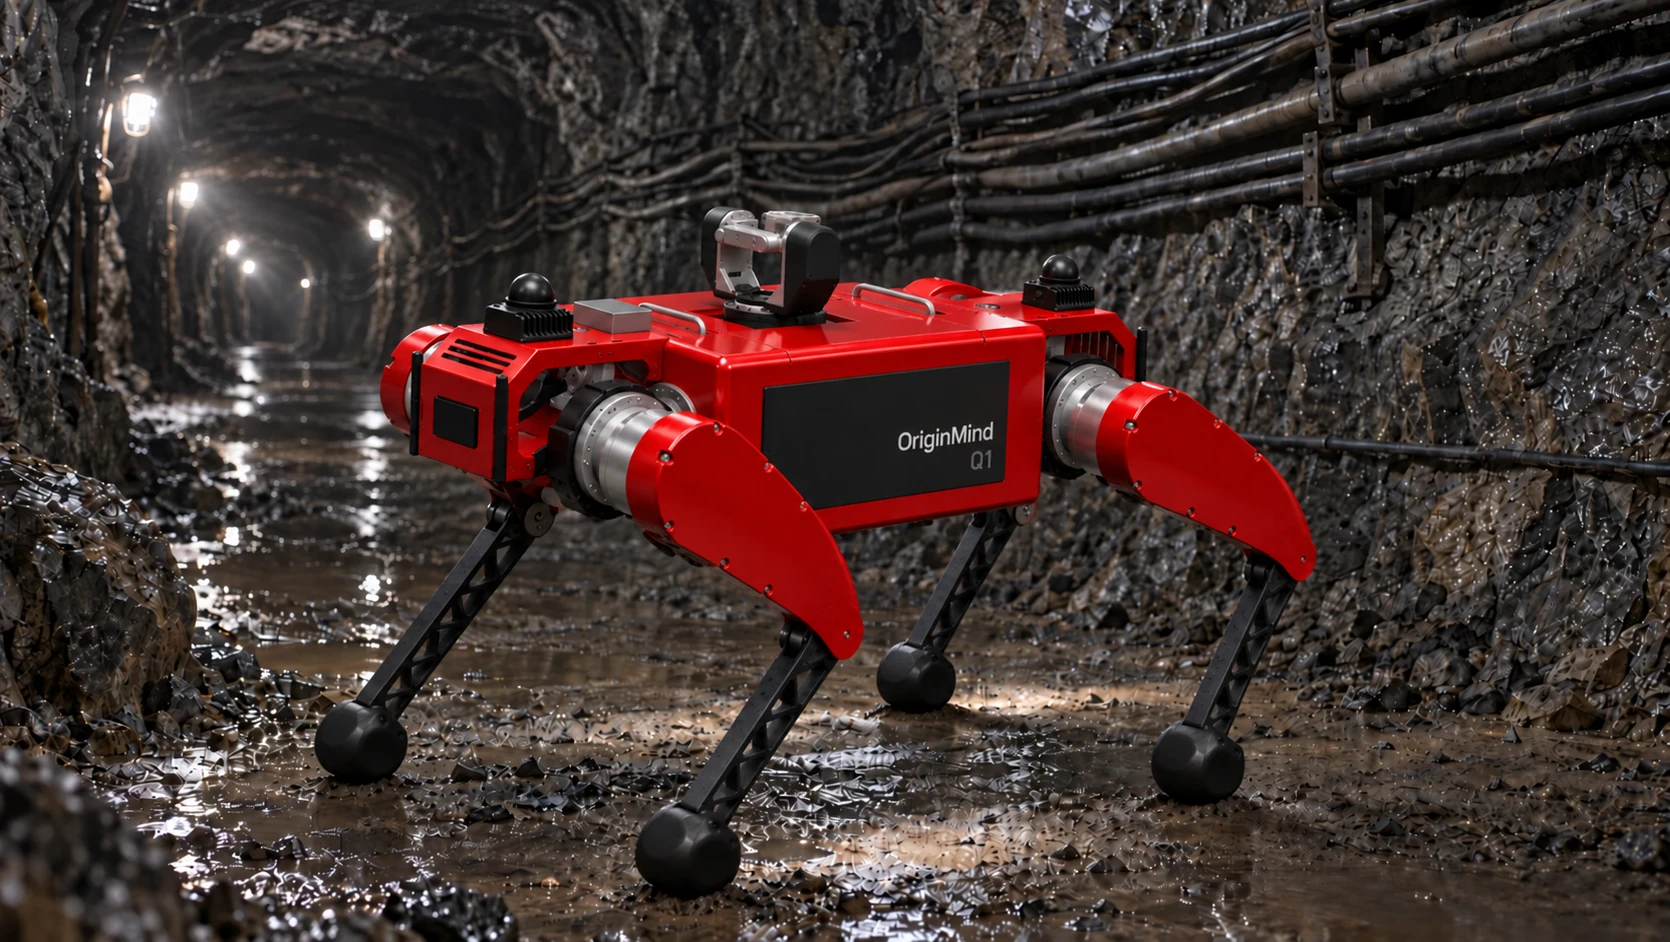
This footage shows an earlier research platform. Q1 remains at the engineering prototype stage.
Underground routes often lack GNSS. Low light, uneven ground and dust also affect navigation and access. Assess passage width, gradients, steps and gravel before selecting the platform, sensors and communications. Test arrival, data capture, record storage and human review in stages.
Provide representative routes, passage dimensions, slopes, steps and ground photographs.
List equipment, inspection locations and the information to capture.
Describe lighting, dust, communications and the areas and times available for testing.