Workstations and objects
Provide workstation dimensions, object details and available operating space.
APPLICATIONS
Develop mobile navigation and dual-arm workflows for handling tasks across workstations.
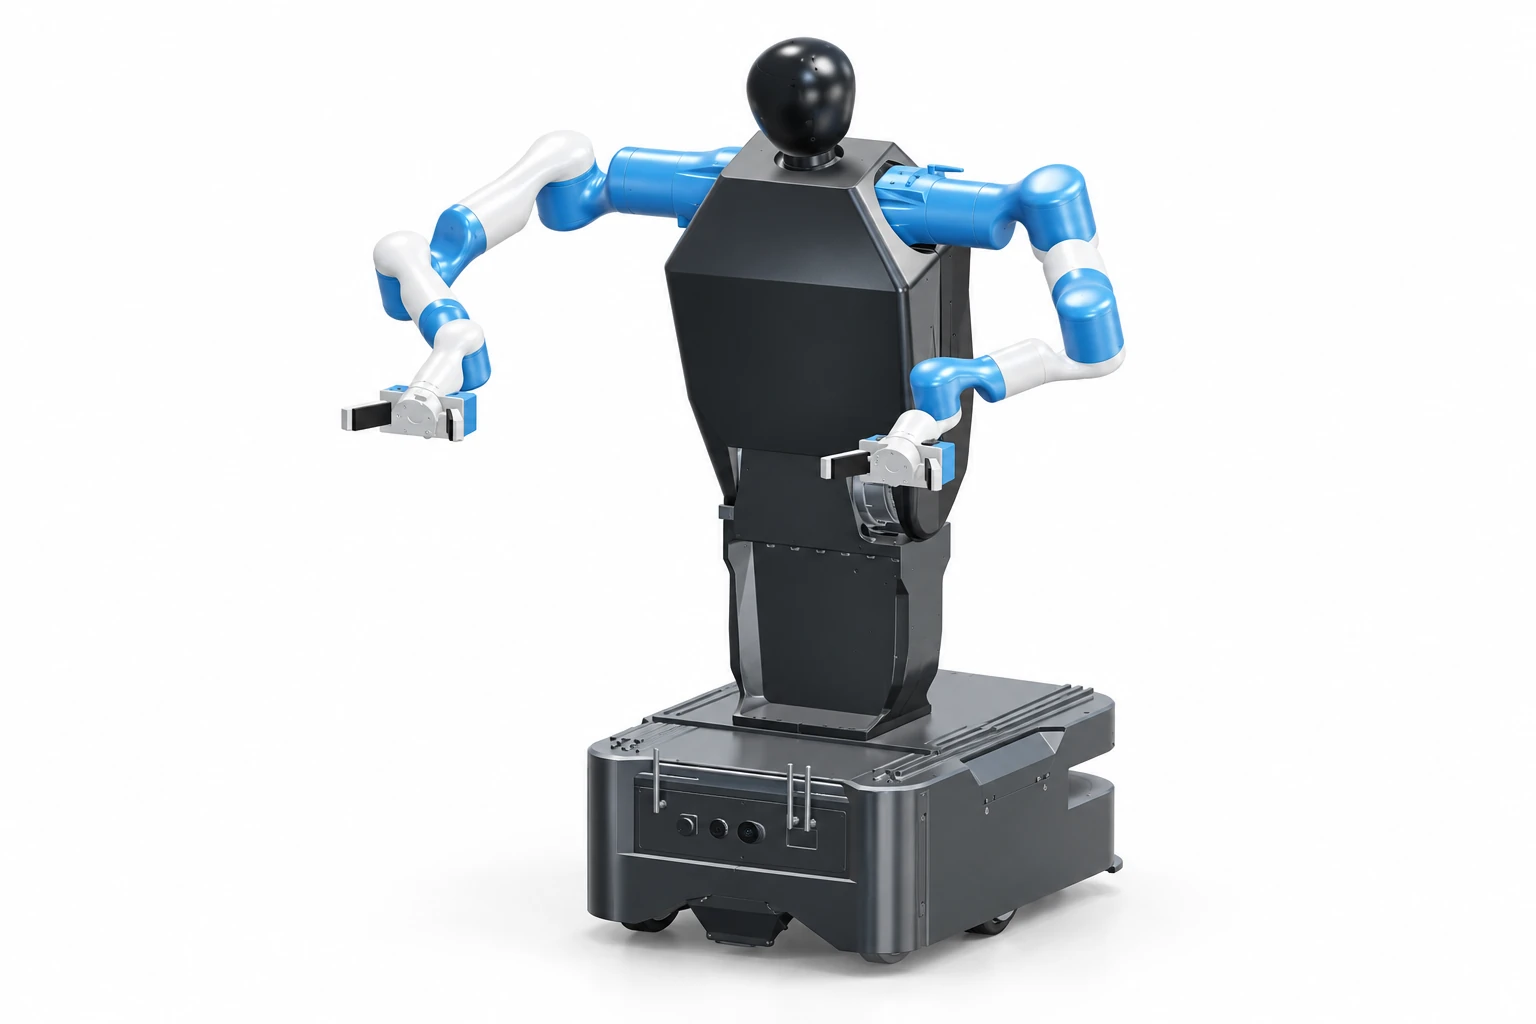
Assess the base, arms, end effectors and perception around the workstation, objects and required actions. Define the transition from arrival and docking to manipulation. Check workspace, joint motion and task sequence in simulation before physical integration.
Provide workstation dimensions, object details and available operating space.
Describe grasping, handling and manipulation steps, including end-effector requirements.
Agree which tasks to simulate first, physical test conditions and the records to retain.